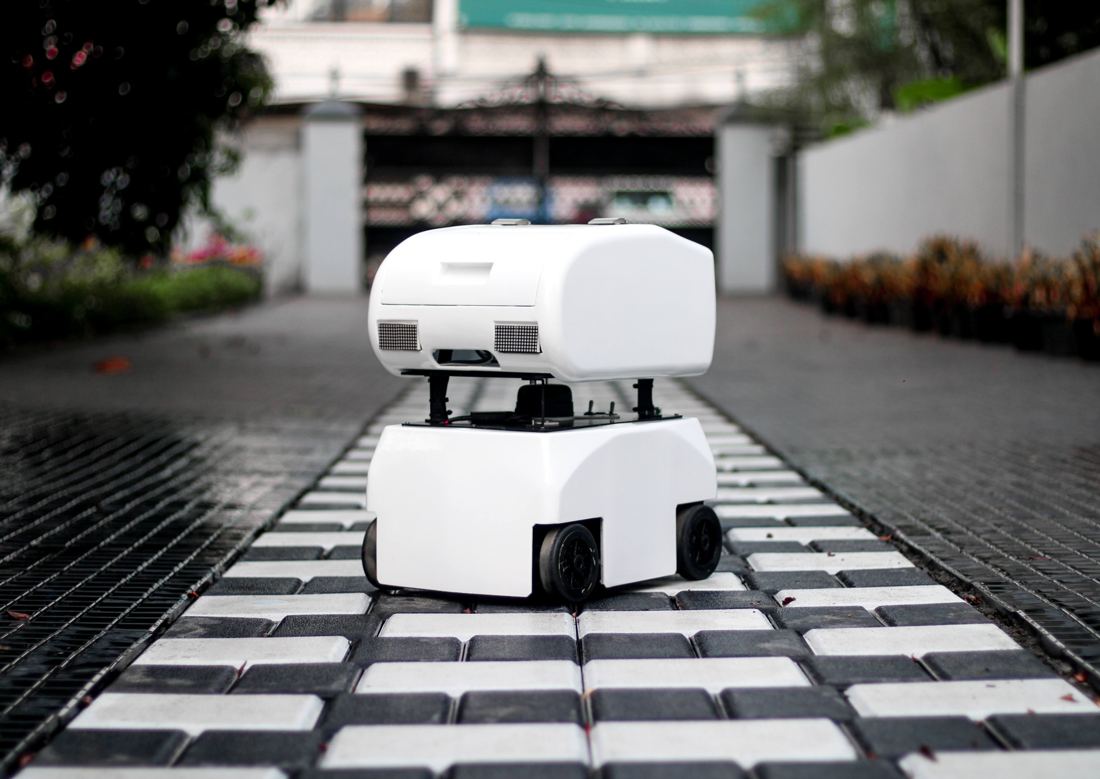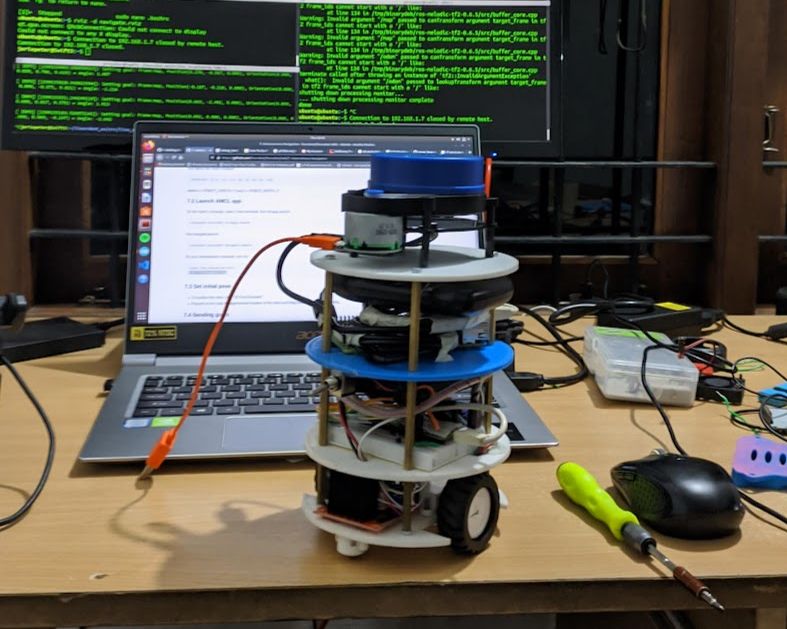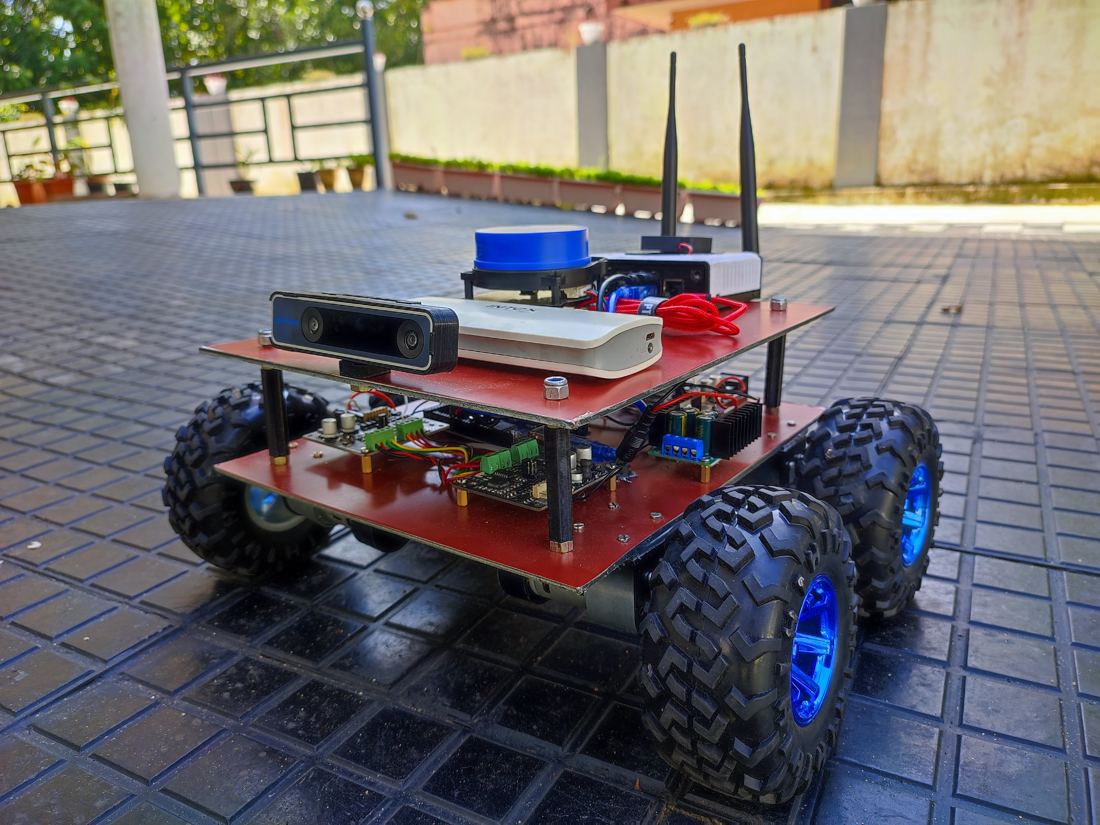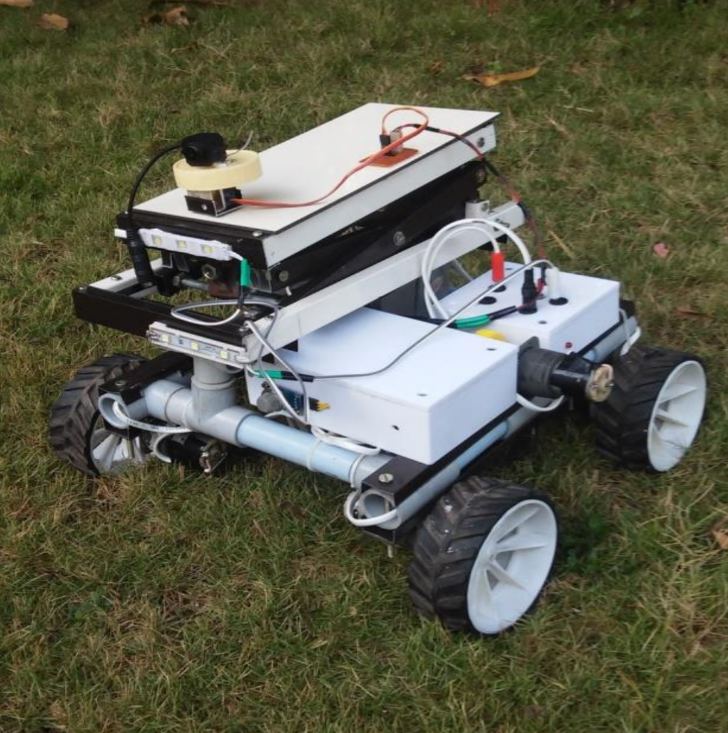
●Robotics Engineer · San Francisco

I take robots from bare hardware to autonomy.

and back to the bench
when they fall over

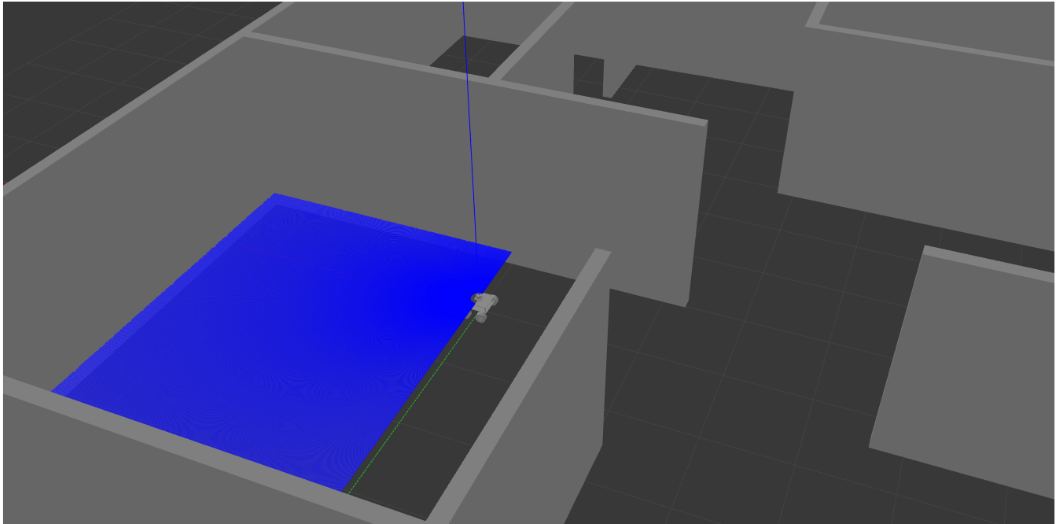
I bring up humanoid and legged robots end to end: sensors, networking and compute first, then SLAM, localization and Nav2, then the AI models that run on top. Currently at OpenMind.

The fleet I have brought up.

OpenMind · San Francisco · Bay 01
UnitClassWhat I didStatus
Unitree G1HumanoidSLAM · Nav2 · GeofenceWalking
Lynx M20 ProQuadrupedICP loc · SLAM · Loop closure · NavOn patrol
Unitree Go2QuadrupedHybrid localizationTrotting
LimX Tron1BipedBring-up · DDSBalancing
AgiBotHumanoidBring-upWaving
Booster K1HumanoidBring-upKicking
Jetson ThorComputeHarness · DDS bridgeThinking
AGX Orin · RPiComputeOnboard computeCrunching
All times local · statuses are mostly trueUpdated 2026
01 · About
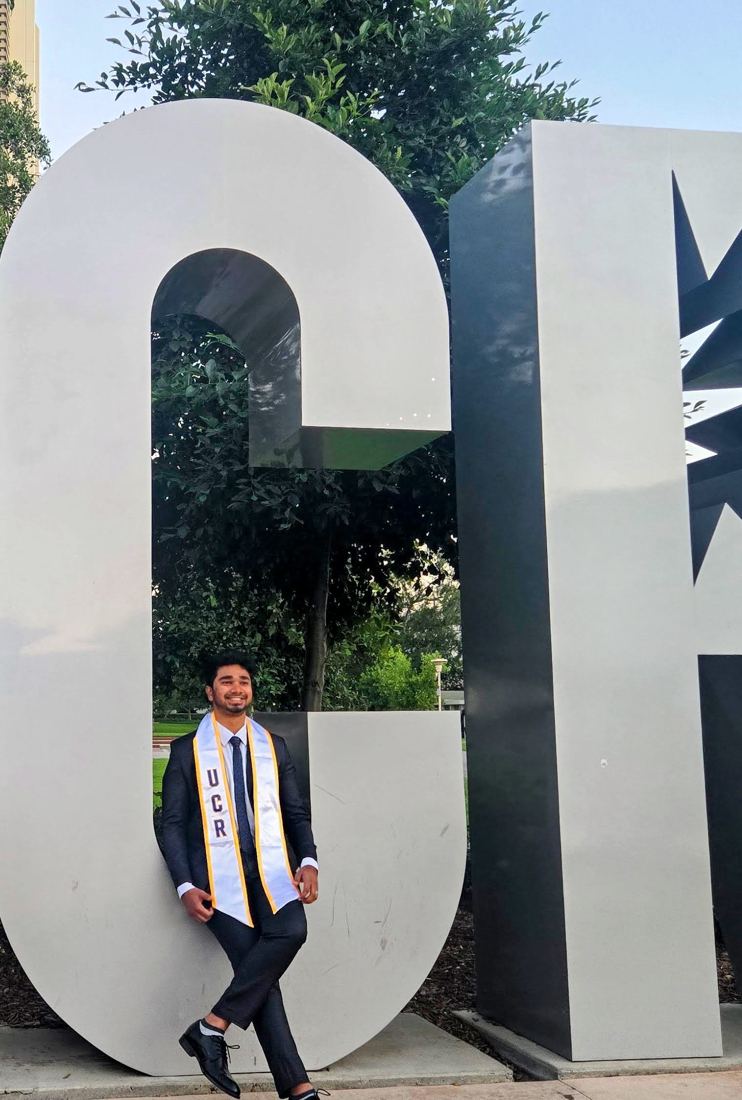
Jerin Peter at UC Riverside on graduation day
UC RiversideM.S. Robotics

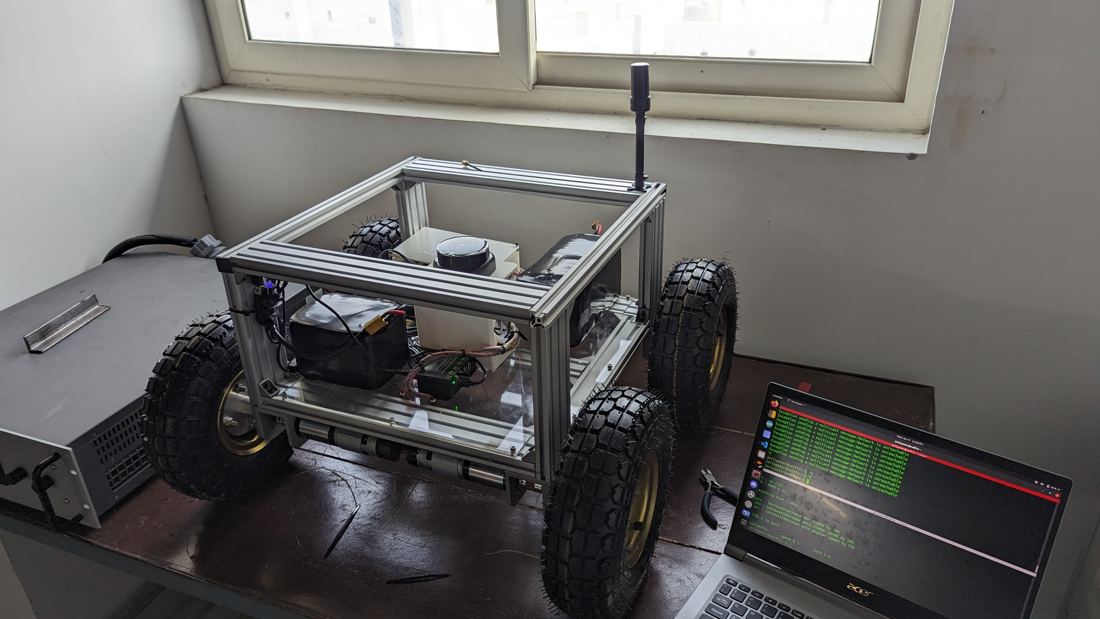
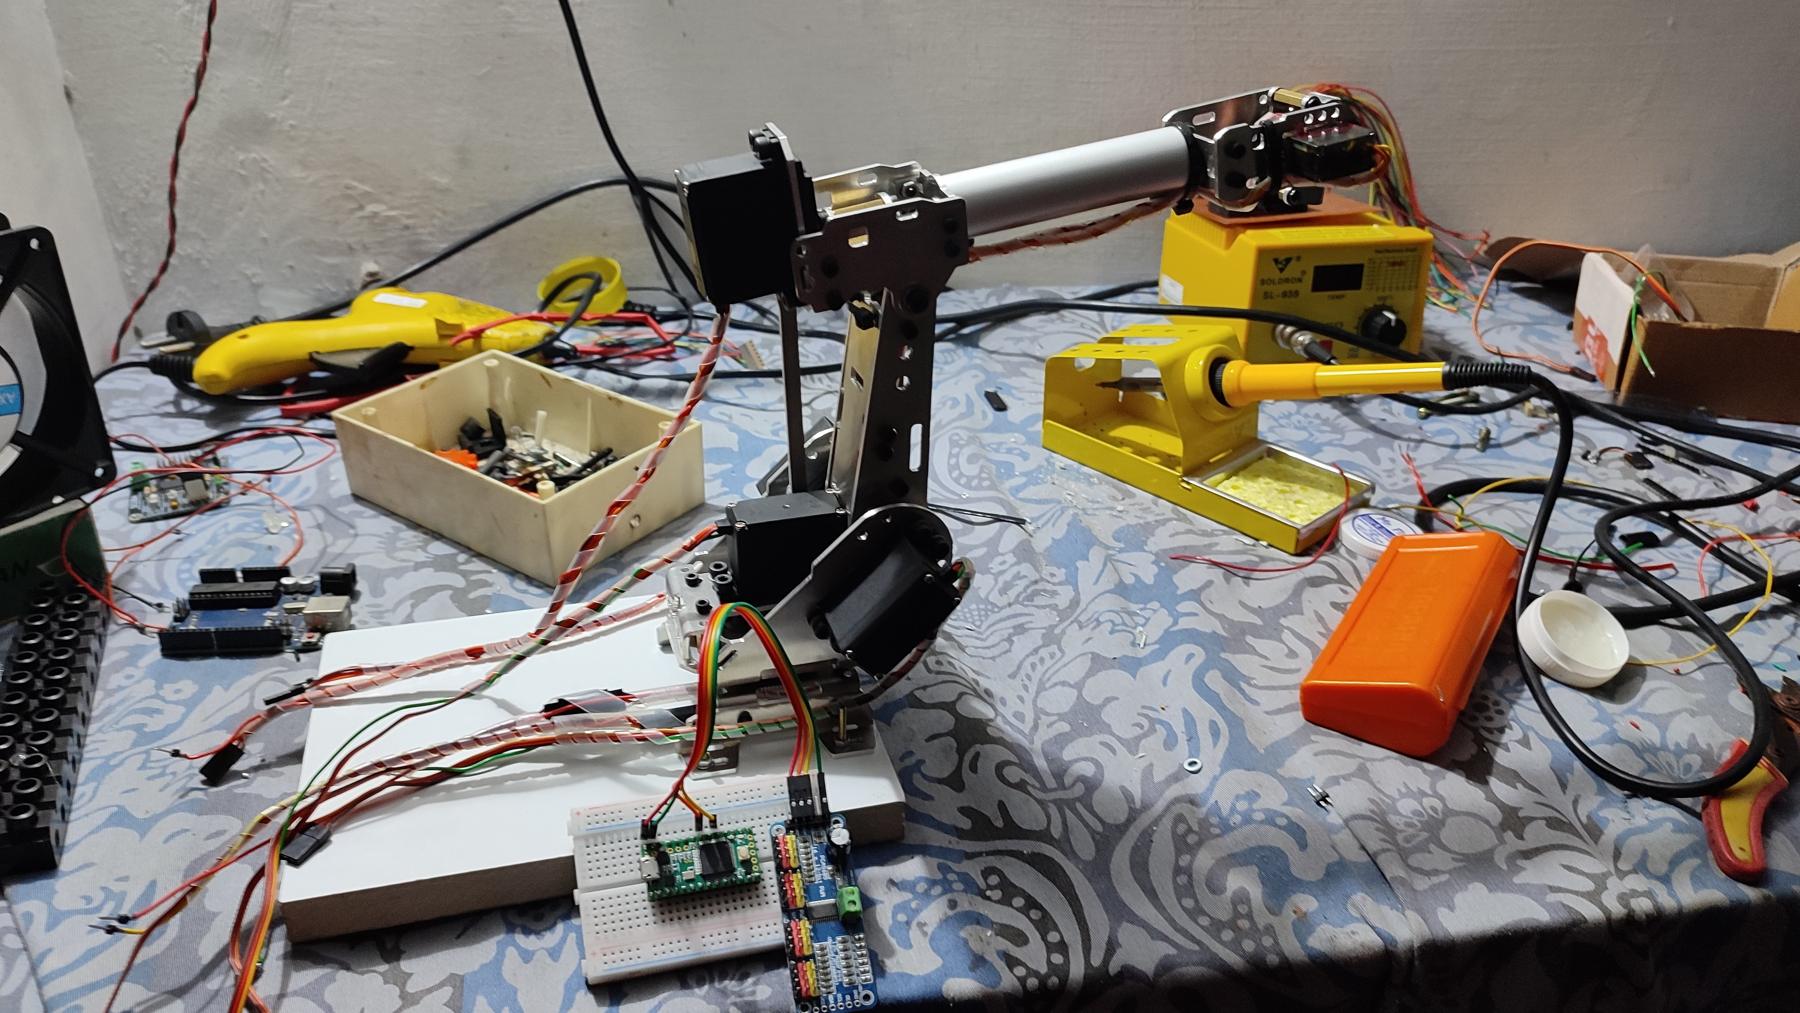
I live at the seam between hardware and software. Hand me a new robot in a crate and I will get it sensing, localizing and navigating, then put the intelligence on top.

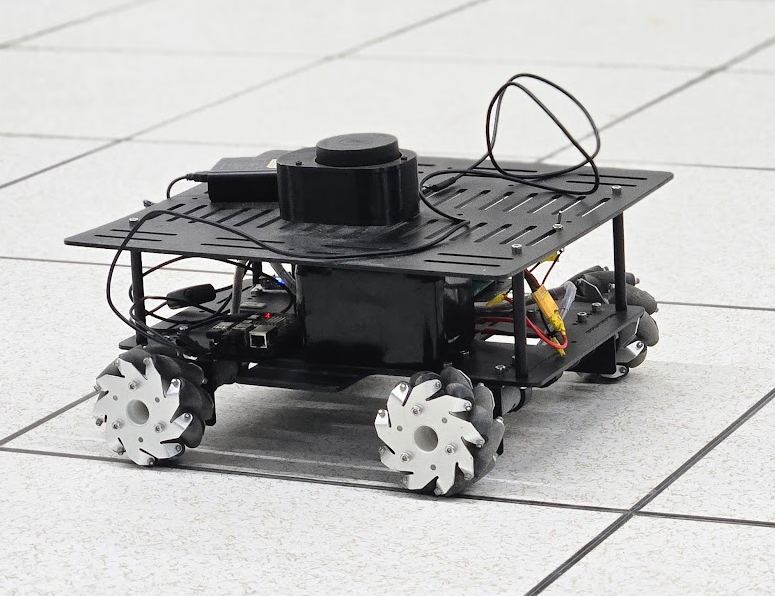
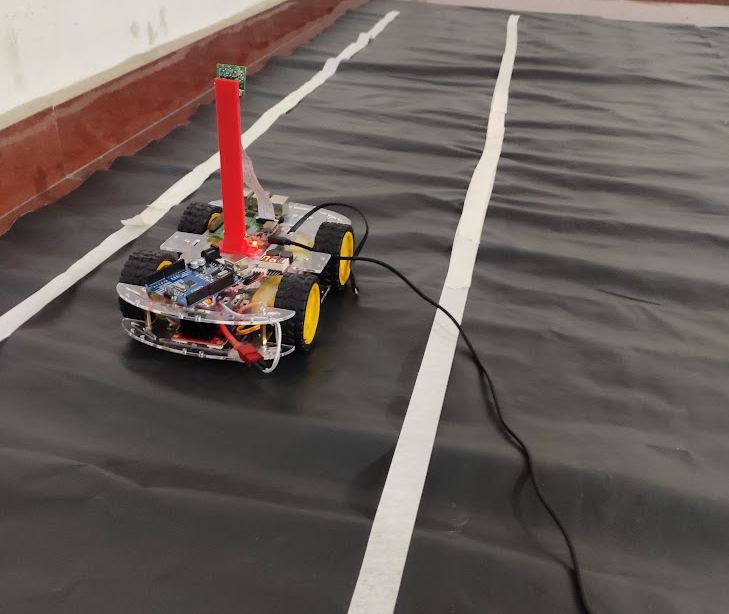
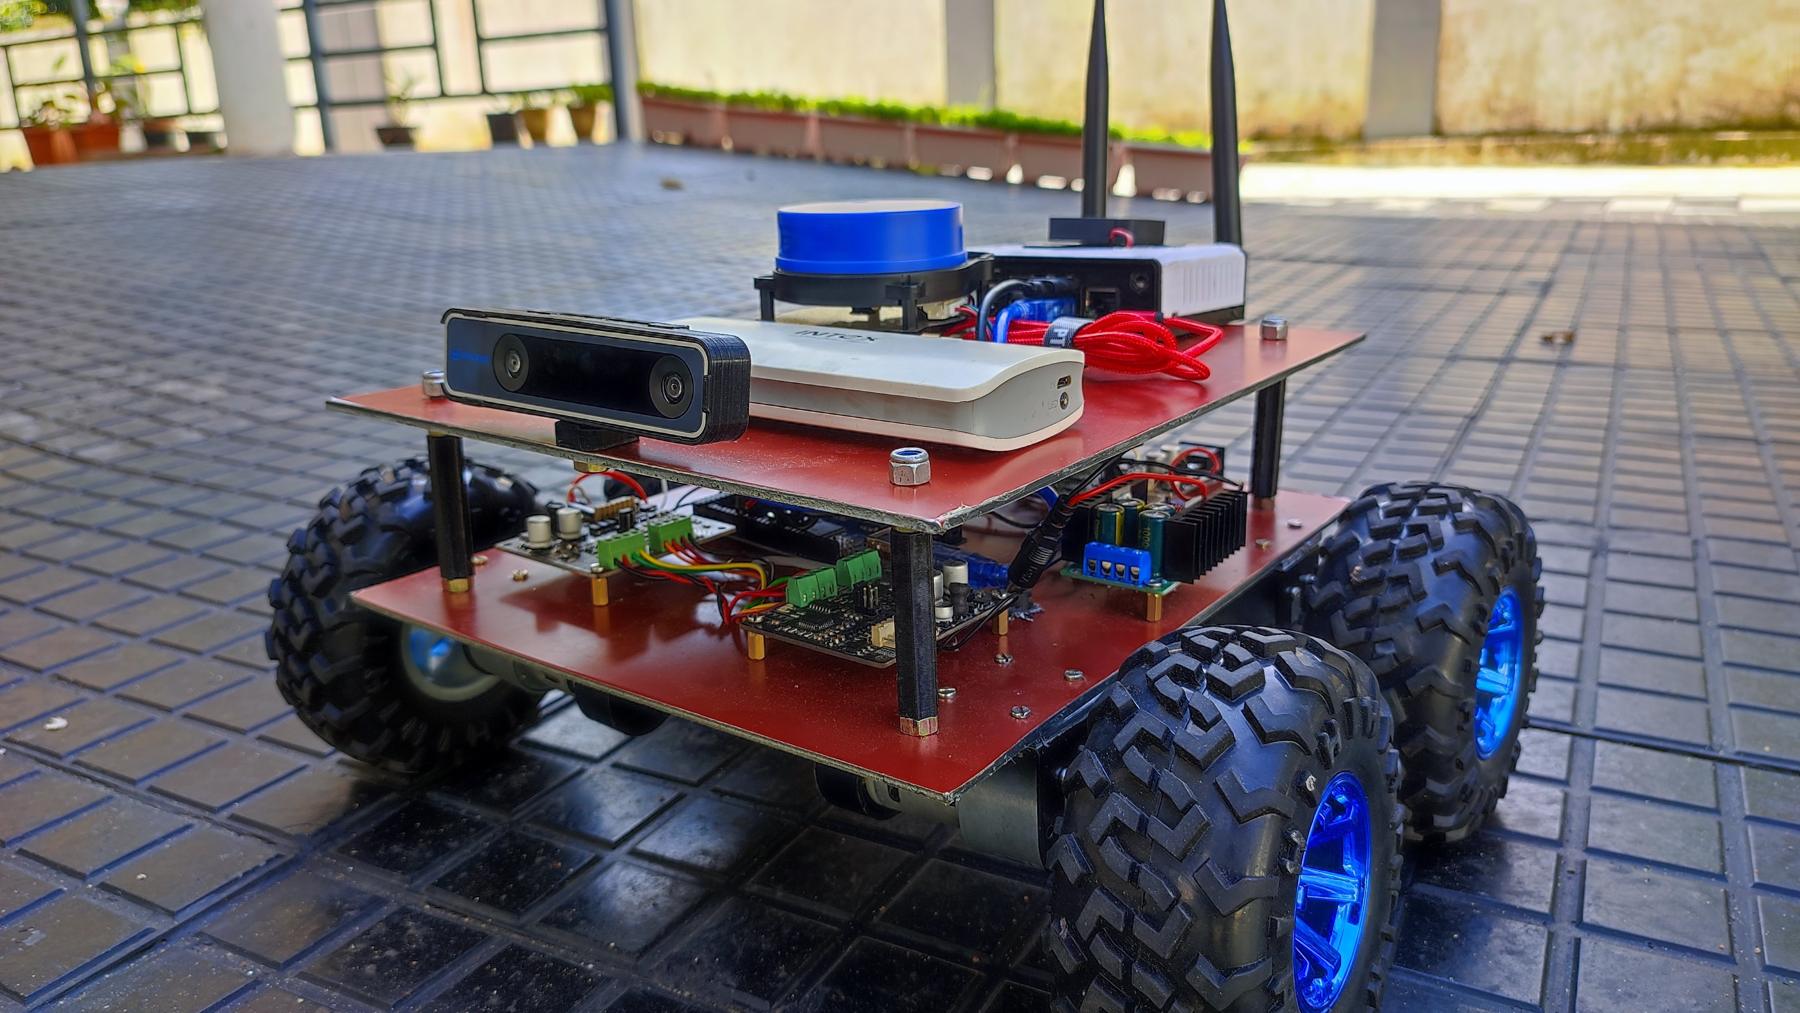
Today that means bringing up humanoid and legged platforms at OpenMind and wiring foundation models into real autonomy. Before that I spent years building wheeled robots from the chassis up, published papers about them, and taught ROS to anyone who would sit still long enough.

+robot platforms brought up
papers, 3 first author
first place wins
+workshops taught
University of California, Riverside · M.S. Robotics, control and navigationGPA 3.88
Rajagiri School of Engineering & Technology · B.Tech Electronics and CommunicationIndia
02 · Now at OpenMind

Systems I build for robots that leave the lab.

Selected work on the OM1 and BrainPack platform, across humanoid, quadruped and biped robots.

02.1Deep Robotics Lynx M20 Pro

Production ready navigation on a quadruped

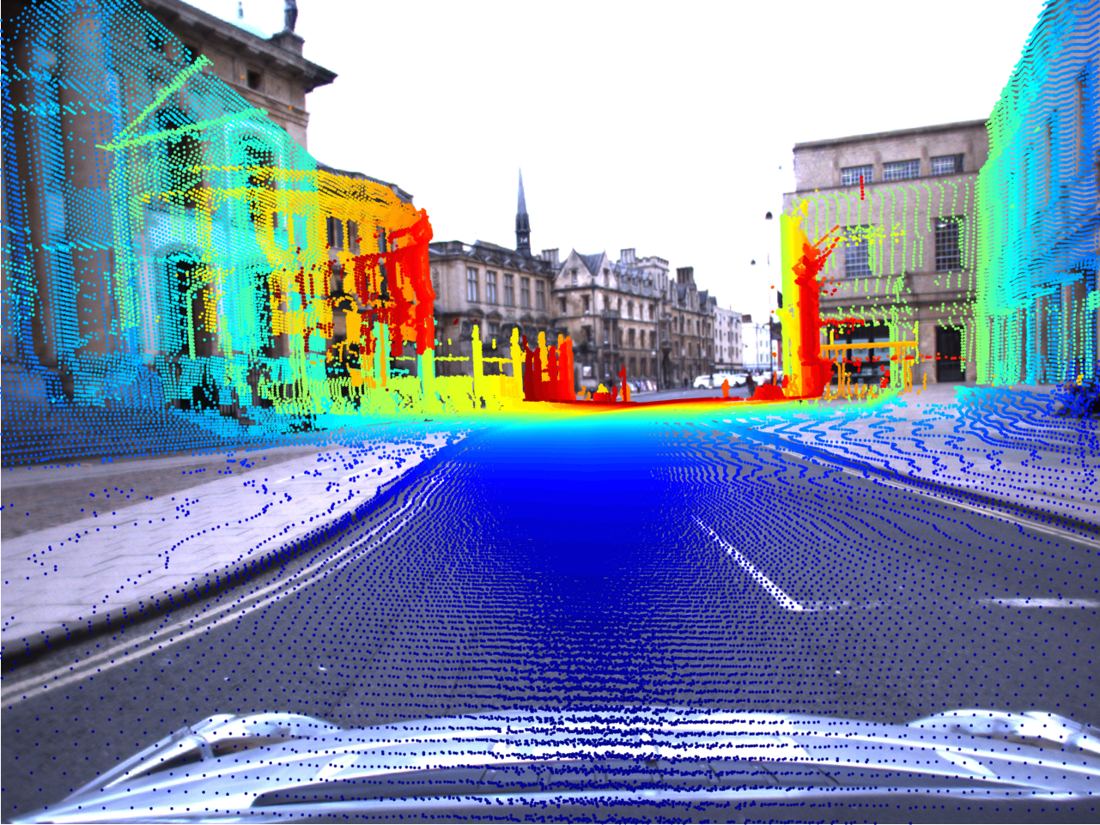
Built the whole navigation stack: ICP based localization and SLAM tuned until it stopped surprising anyone, loop closure so long runs stay consistent, and Nav2 tuned end to end. Production ready for real autonomous work like delivery and inspection, not just demos.

ICP localizationSLAMLoop closureNav2
02.2Unitree Go2

Hybrid localization that knows when it is lost

A Numba accelerated correlative scan matcher fused with Nav2 AMCL and visual place recognition voting. A five state health monitor decides who owns the map to odom transform.

PythonNumbaAMCLVPR
02.3Unitree G1

Humanoid SLAM, navigation and geofencing

RTAB-Map on a Livox Mid-360 with persistent maps and Nav2 in localization mode. Tuned MPPI and SmacPlannerHybrid, and added GeoJSON no go zones for the person follower.

RTAB-MapNav2MPPIShapely
02.4Thor · Orin · RPi

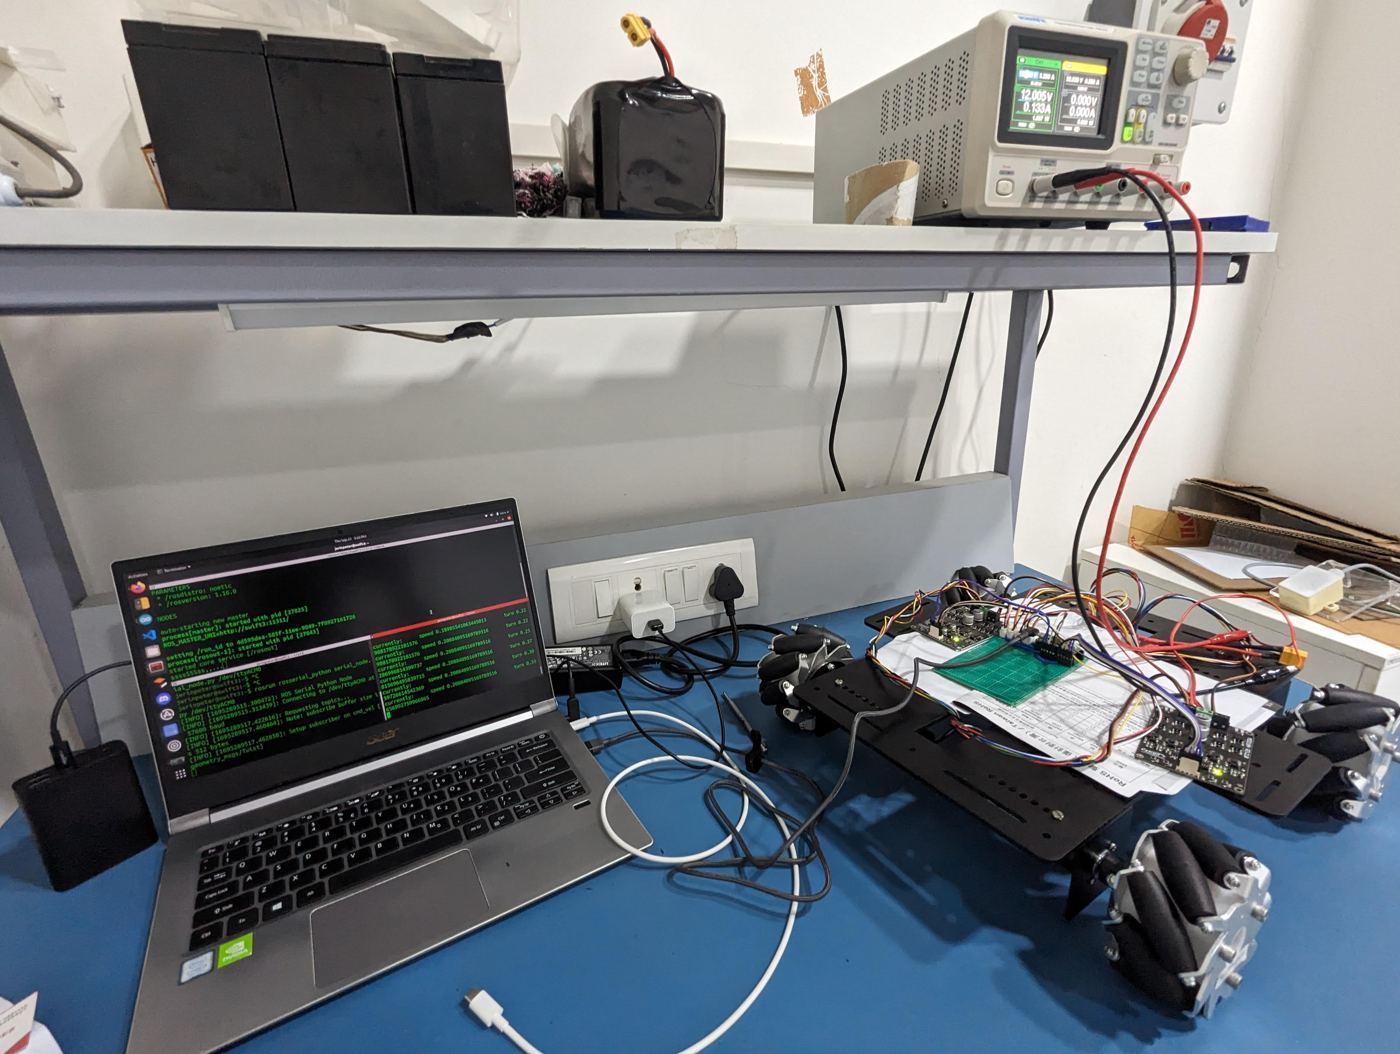
Hardware bring-up from the pinout up

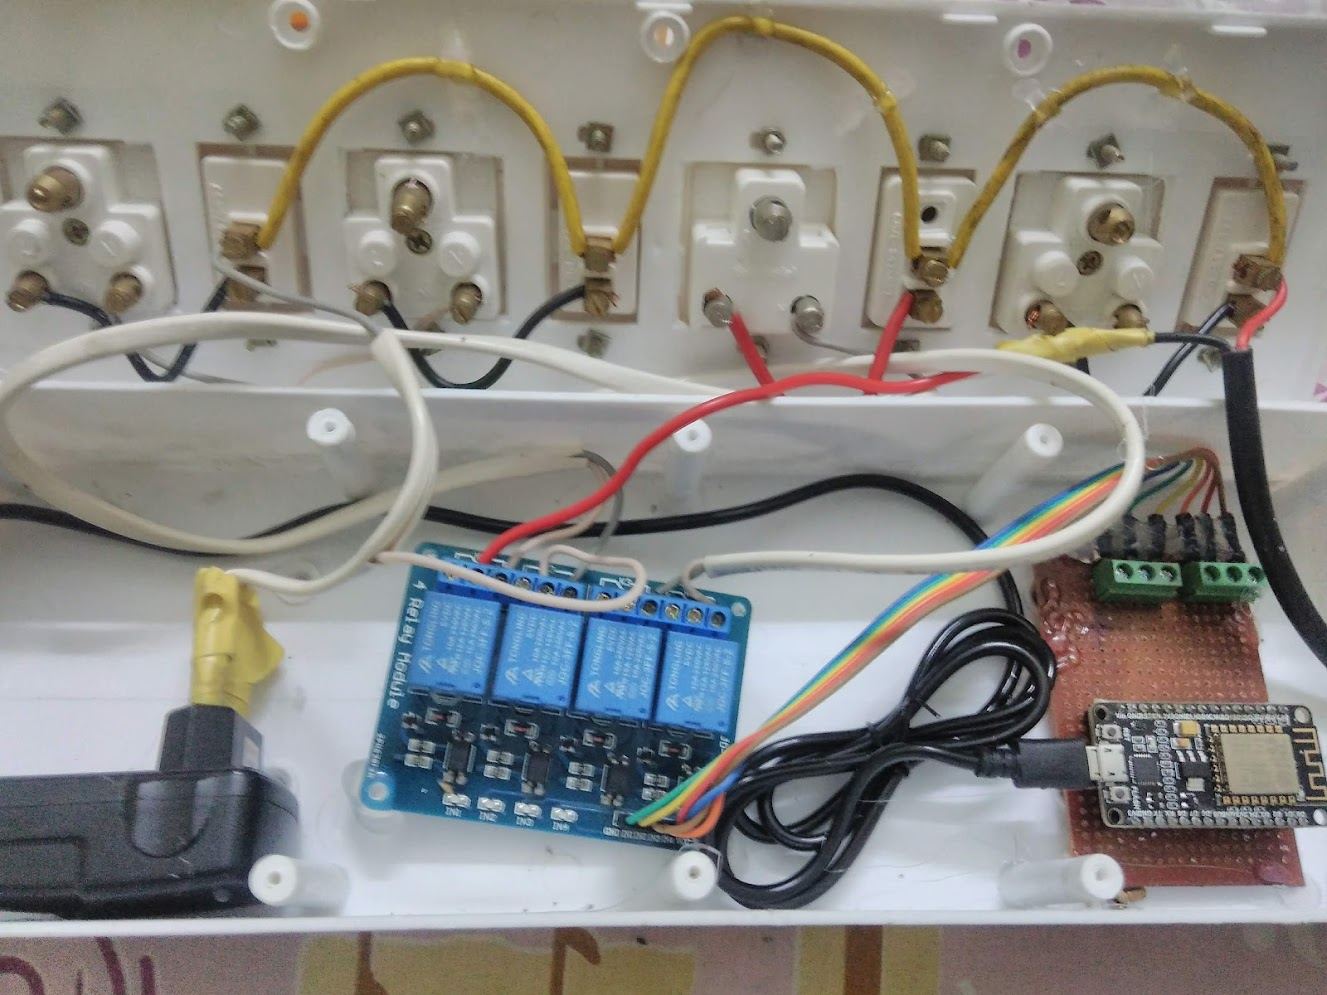
Decoded proprietary robot harnesses, crimped the network, and bridged Unitree and LimX robots to Jetson Thor, AGX Orin and Raspberry Pi compute over DDS. Traced a LiDAR cable fault with an oscilloscope.

DDSZenohEthernetOscilloscope
02.5OM1 · BrainPack

Foundation models on the robot

Connecting LLM, VLM and VLA models to autonomous behavior, and running local inference on Jetson Orin, Thor and DGX Spark with vLLM and llama.cpp.

LLMVLMvLLMEdge AI

The stack, bottom to top.

I work every layer, from the crimp tool to the language model.

L4
IntelligenceWhat the robot decides
LLM · VLM · VLAvLLMllama.cppPyTorchOpenCVIsaac Sim
L3
AutonomyWhere am I, where to go
Nav2MPPISmacPlannerRTAB-MapSLAM ToolboxFAST-LIOICPAMCLEKFRTK GPSOpen-RMF
L2
MiddlewareHow the parts talk
ROS 2ZenohCyclone DDSPythonNumbaDockerFlaskFoxgloveGazebo
L1
HardwareWhat I crimp, wire and probe
Jetson ThorAGX OrinRaspberry PiLivox Mid-360RealSenseRPLidarESP32STM32TeensyI2C · SPI · UART · CAN
03 · Experience

Six years of making robots move.

Sep 2025 · NowSan Francisco

OpenMind AGI

Robotics Engineer

  • Bring up humanoid and legged robots (Unitree G1 and Go2, LimX Tron1, Deep Robotics Lynx M20 Pro) on the OM1 and BrainPack platform: sensors, DDS networking and onboard compute (Jetson Thor, AGX Orin, Raspberry Pi).
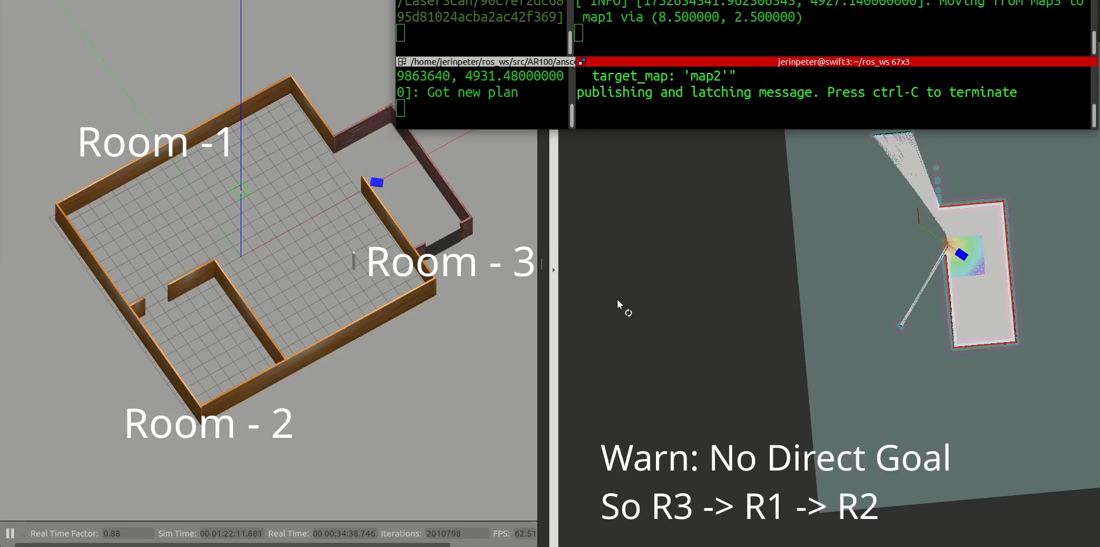
  • Made Lynx M20 Pro navigation production ready: ICP localization, SLAM with loop closure, and end to end Nav2 tuning for delivery and inspection use cases.
  • Built a hybrid localization stack for the Go2 and RTAB-Map SLAM with Nav2 for the G1.
  • Integrate LLM, VLM and VLA models with autonomous navigation and behavior on real hardware.
2024 · 2025Riverside, CA

University of California, Riverside

M.S. Robotics · Teaching Assistant · Summer camp instructor

  • Teaching Assistant: ran the lab sessions for Circuits and Electronics (EE005) and the discussion sessions teaching MATLAB for EE020B, Linear Methods for Engineering Analysis and Design.
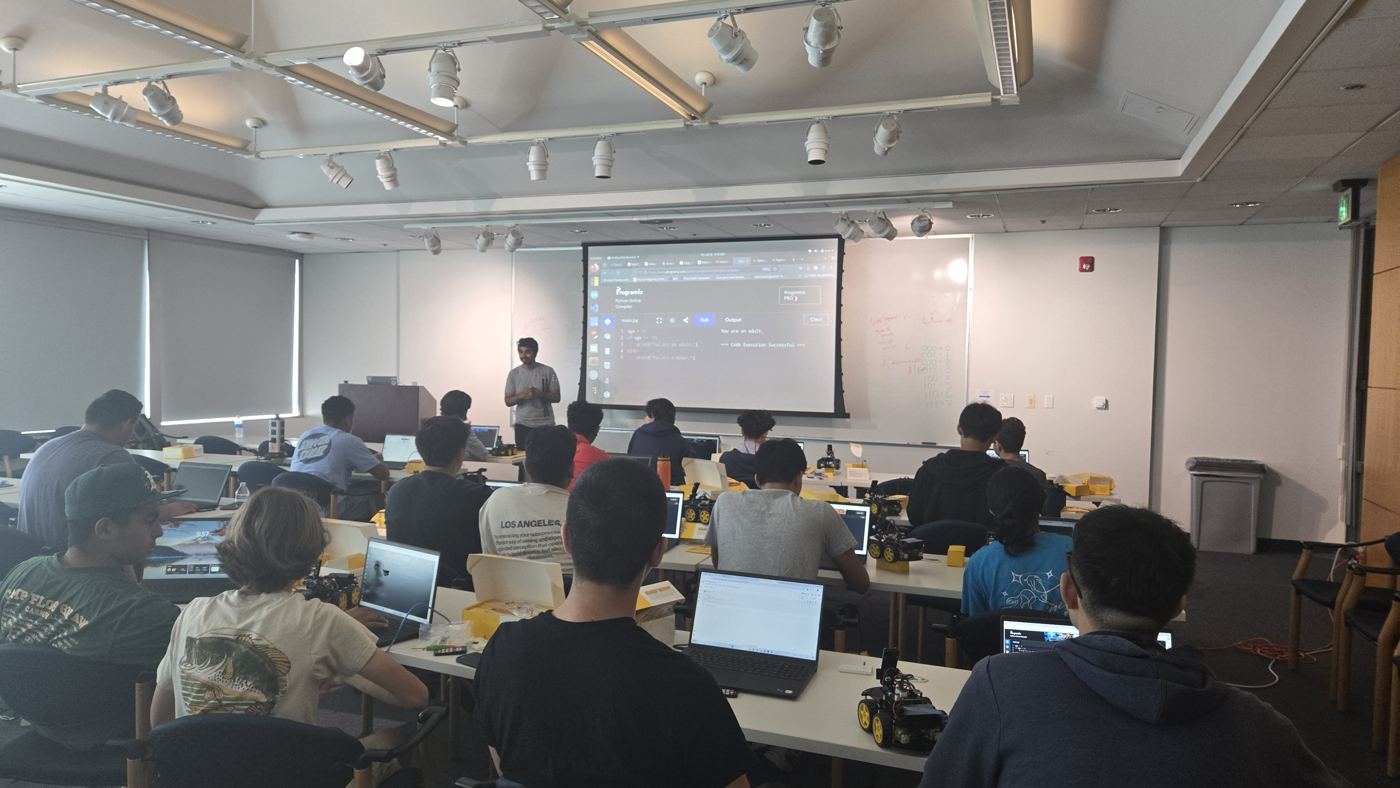
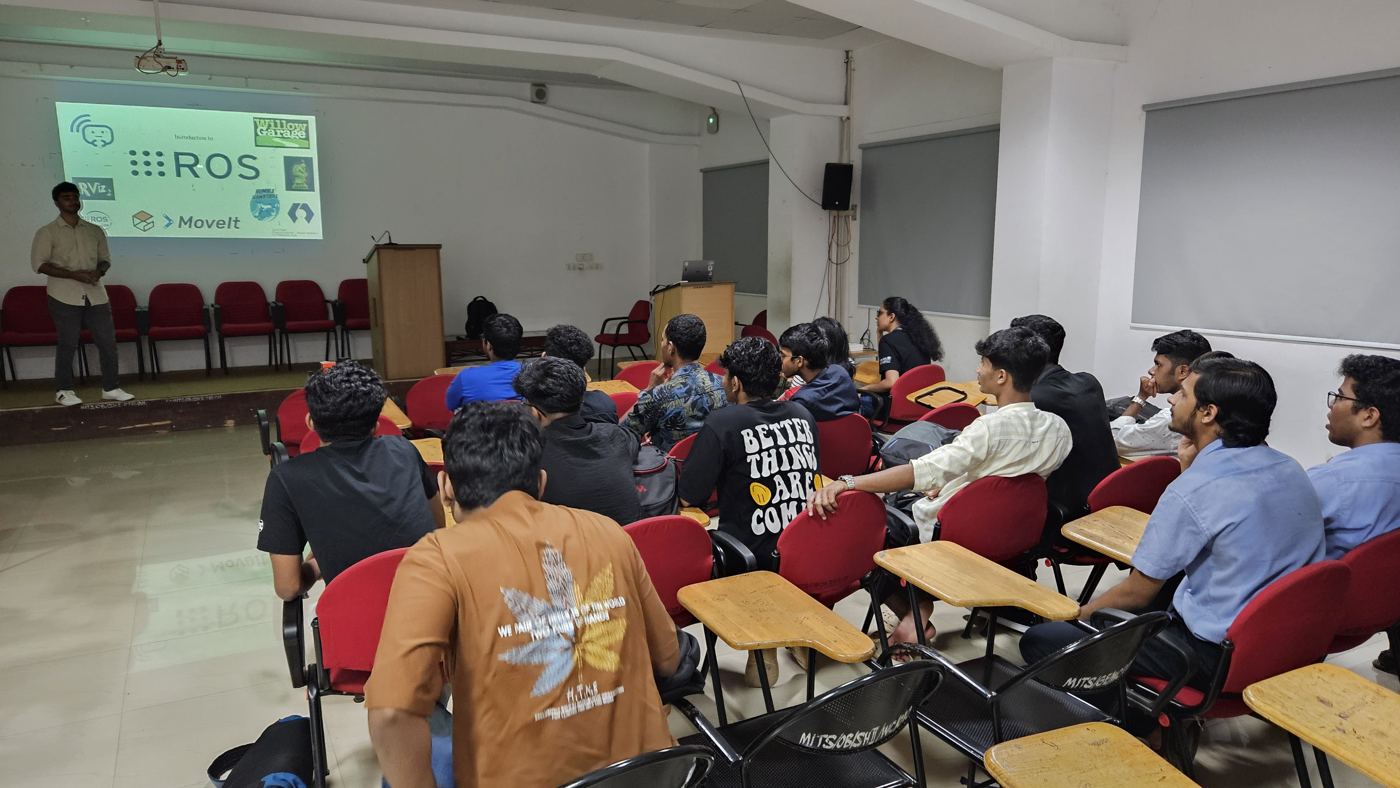
  • Designed the curriculum and taught ROS fundamentals at the BCOE Robotics Summer Camp.
  • Coursework in optimal control and estimation, kinematics and dynamics, and reinforcement learning.
Jul 2023 · Feb 2024Palakkad, India

IIT Palakkad Technology IHub Foundation
Project Engineer, Mobile Robotics

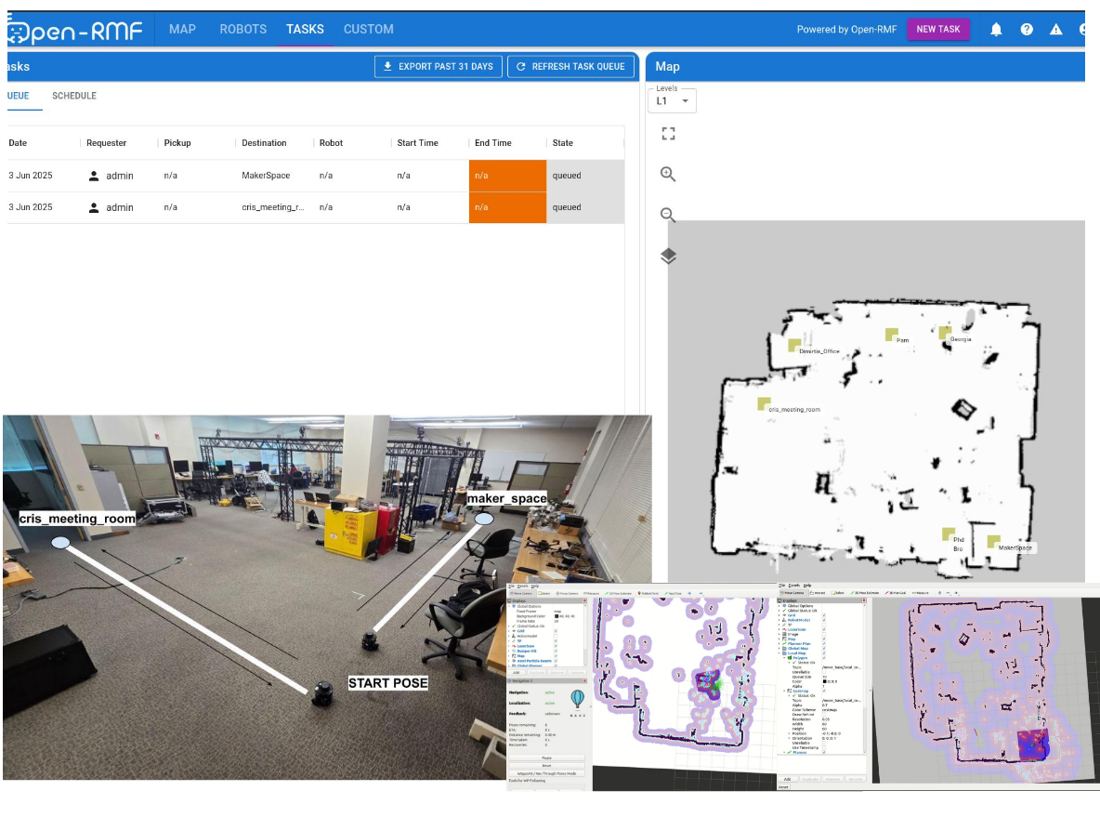
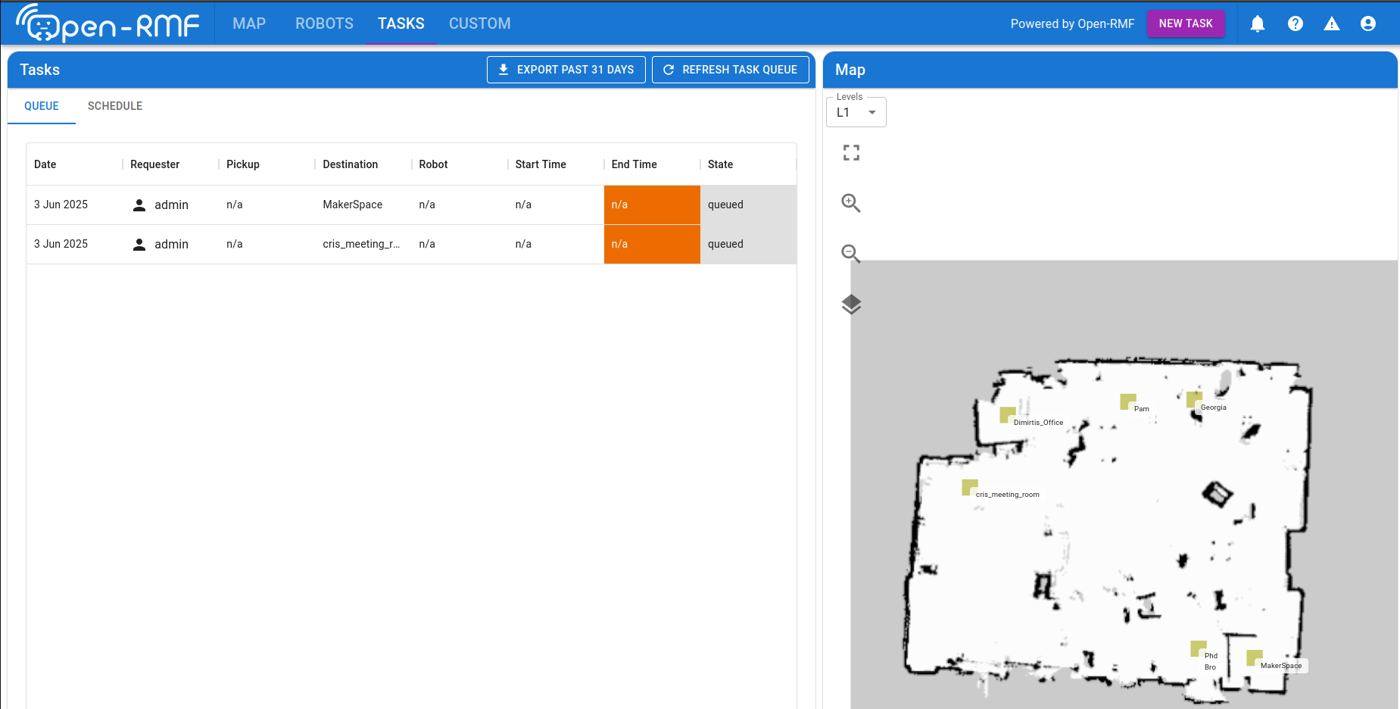
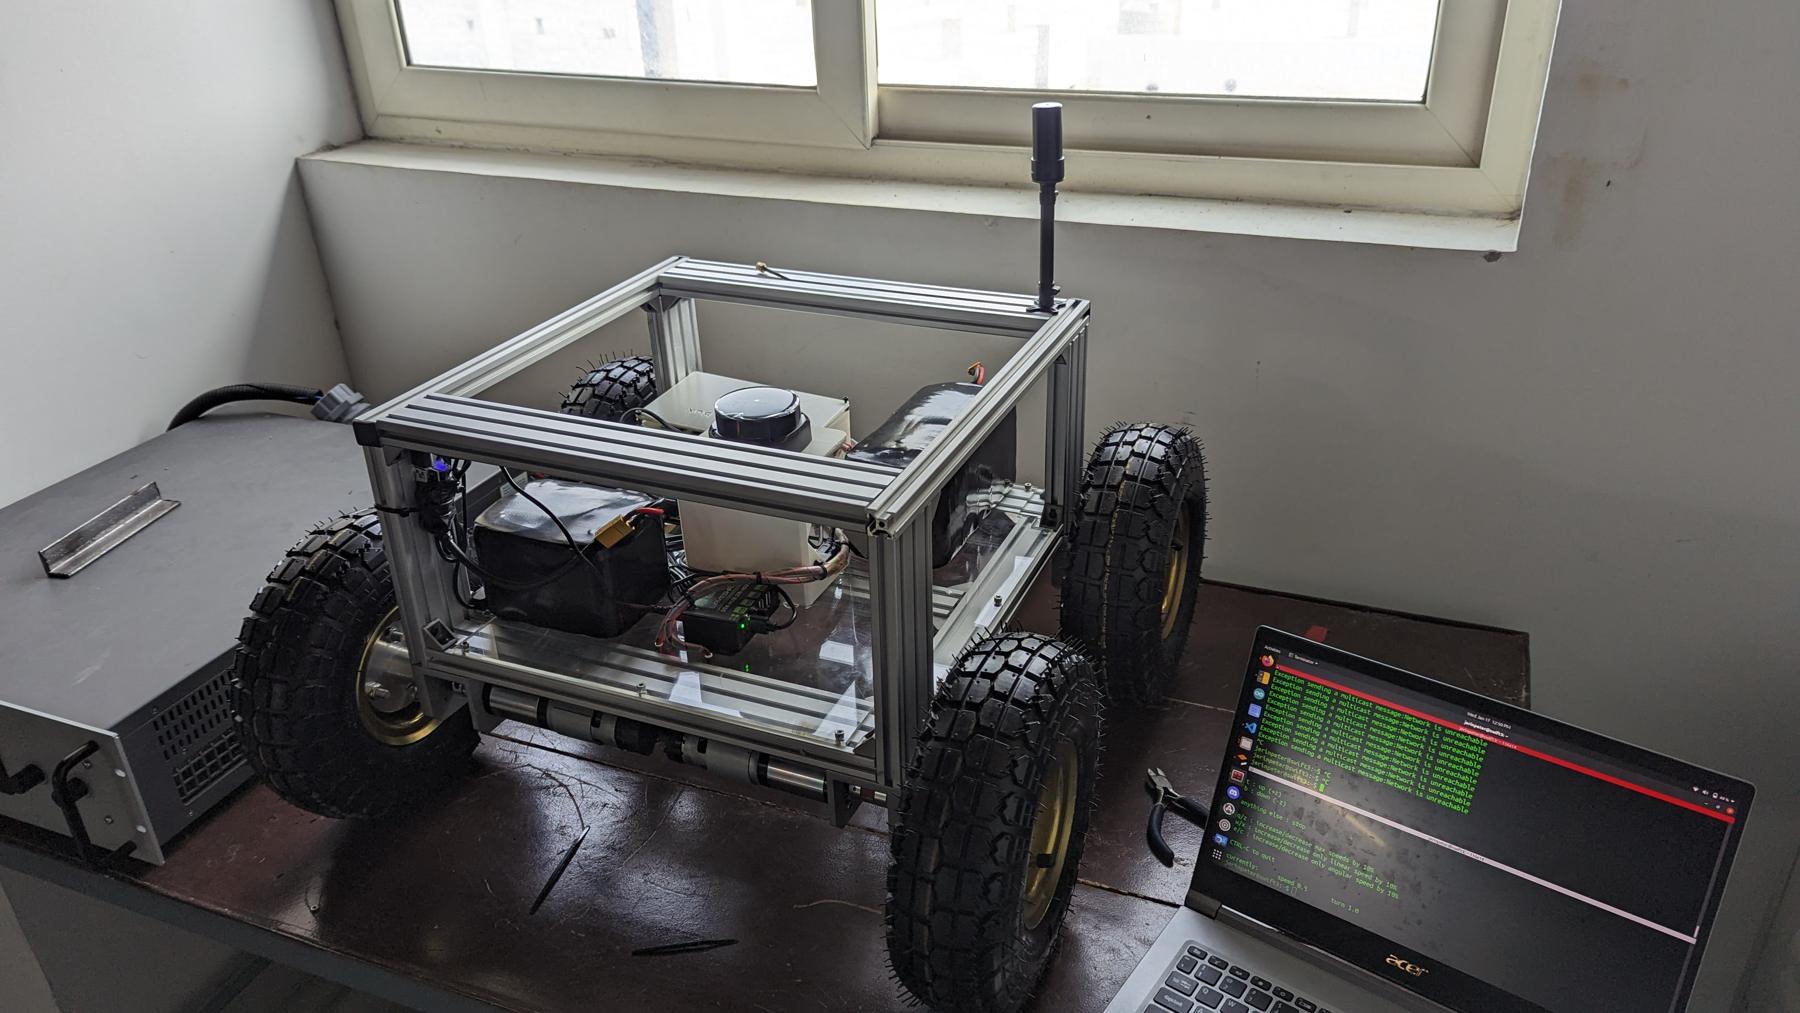
  • Built a modular ROS 2 control stack with Nav2 integration and Open-RMF fleet coordination.
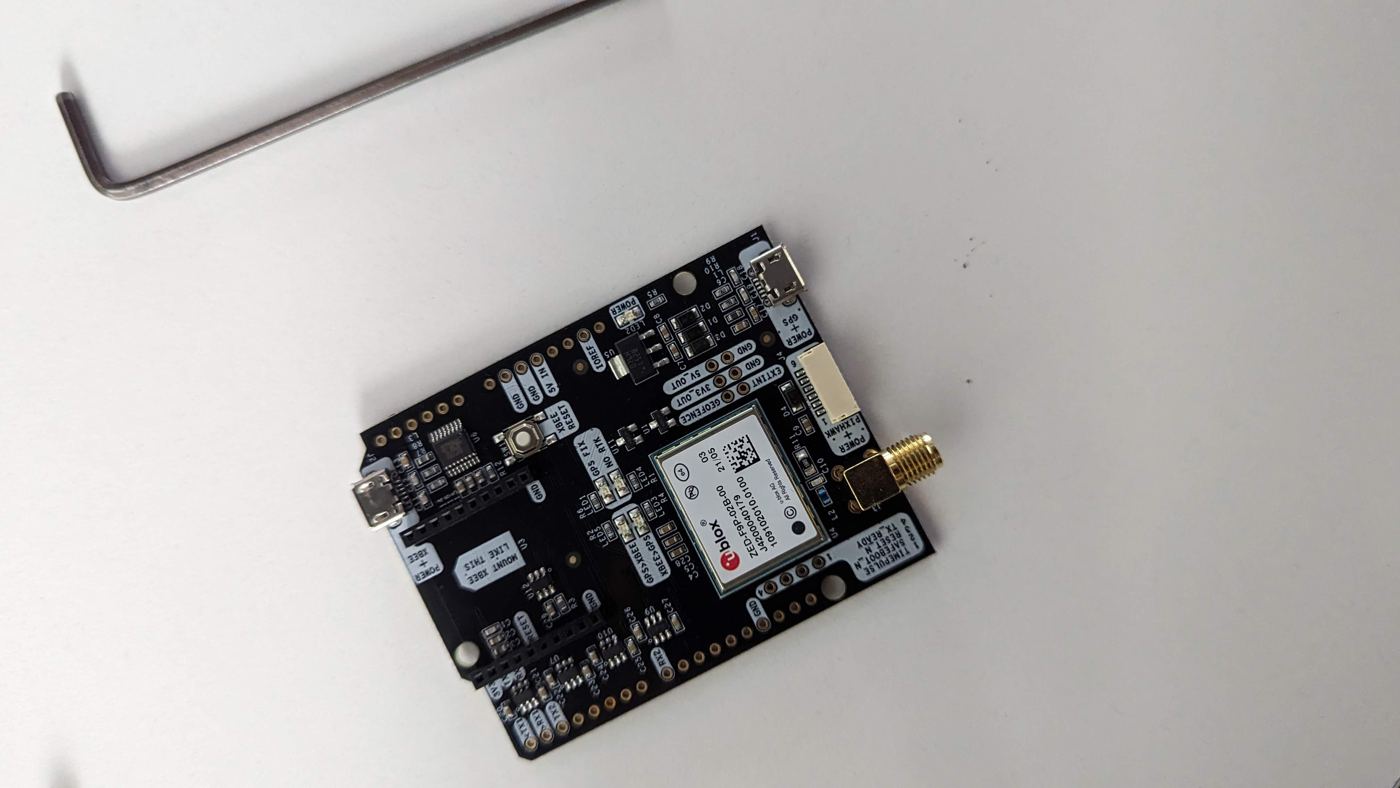
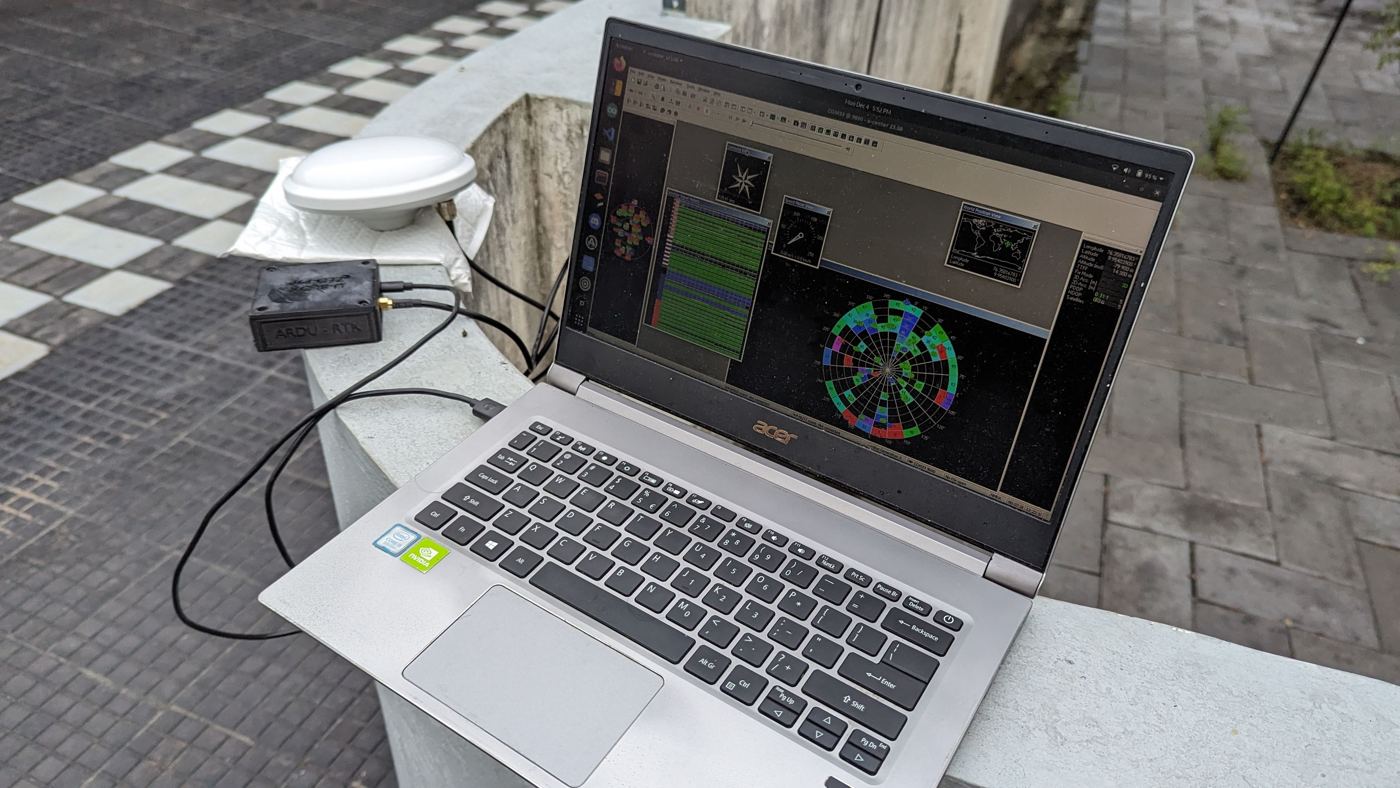
  • Fused RTK GPS, IMU and wheel odometry with an EKF for outdoor navigation.
Aug 2022 · Jun 2023Kochi, India

Asimov Robotics

Software Intern, ROS Developer

  • Migrated legacy ROS nodes to ROS Noetic on Ubuntu 20.04, with documentation.
  • Developed sensor fusion workflows and calibration tools.
Aug 2021 · Oct 2021Hyderabad, India

TiHAN, IIT Hyderabad

Research Assistant

  • Autonomous ground vehicle research and dataset collection tools for navigation stacks.
Feb 2020 · Sep 2020India

Augsense Labs
Software Intern, ROS Developer

  • Research and development on SLAM and navigation using ROS.
05 · Research & honors
Published, presented, and occasionally first place.

1st Prize
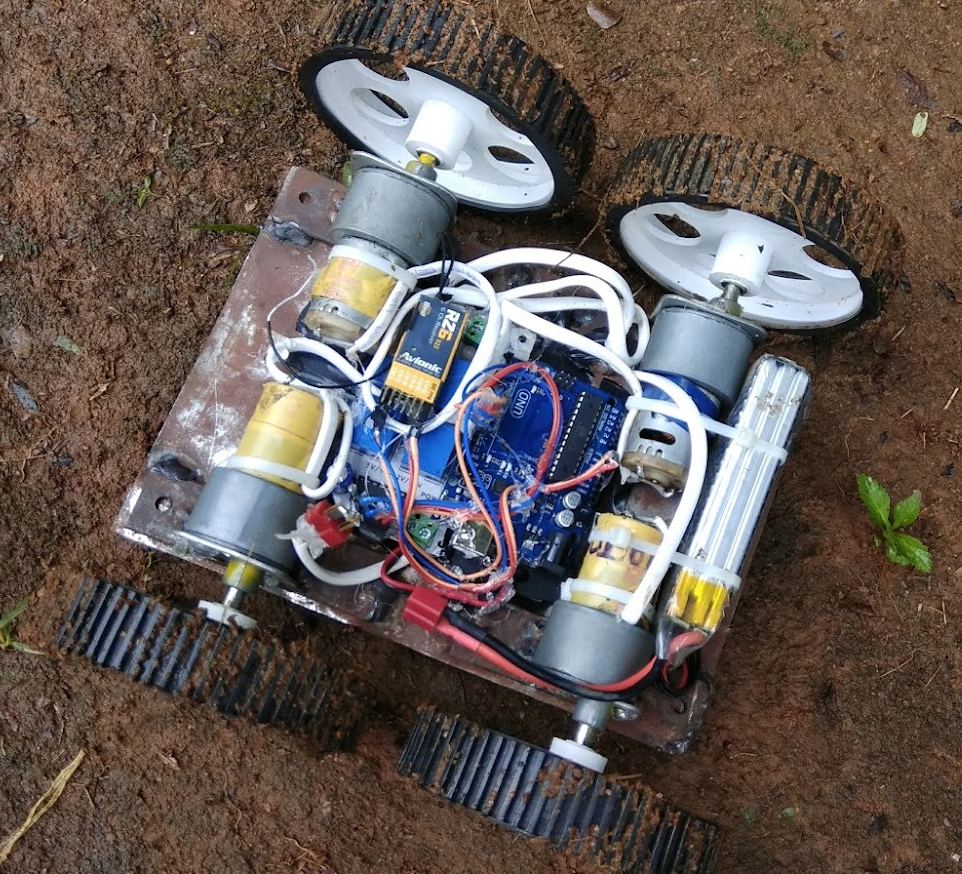
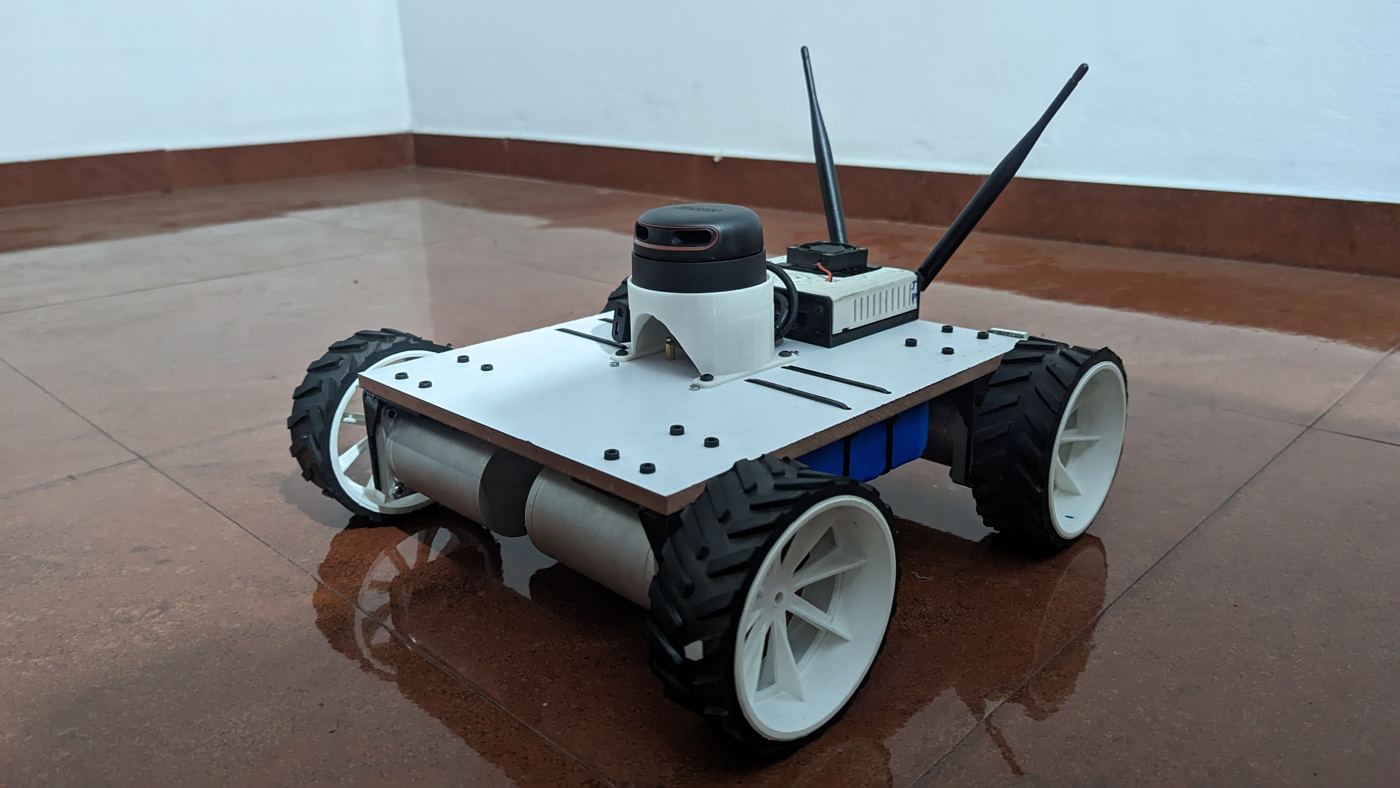
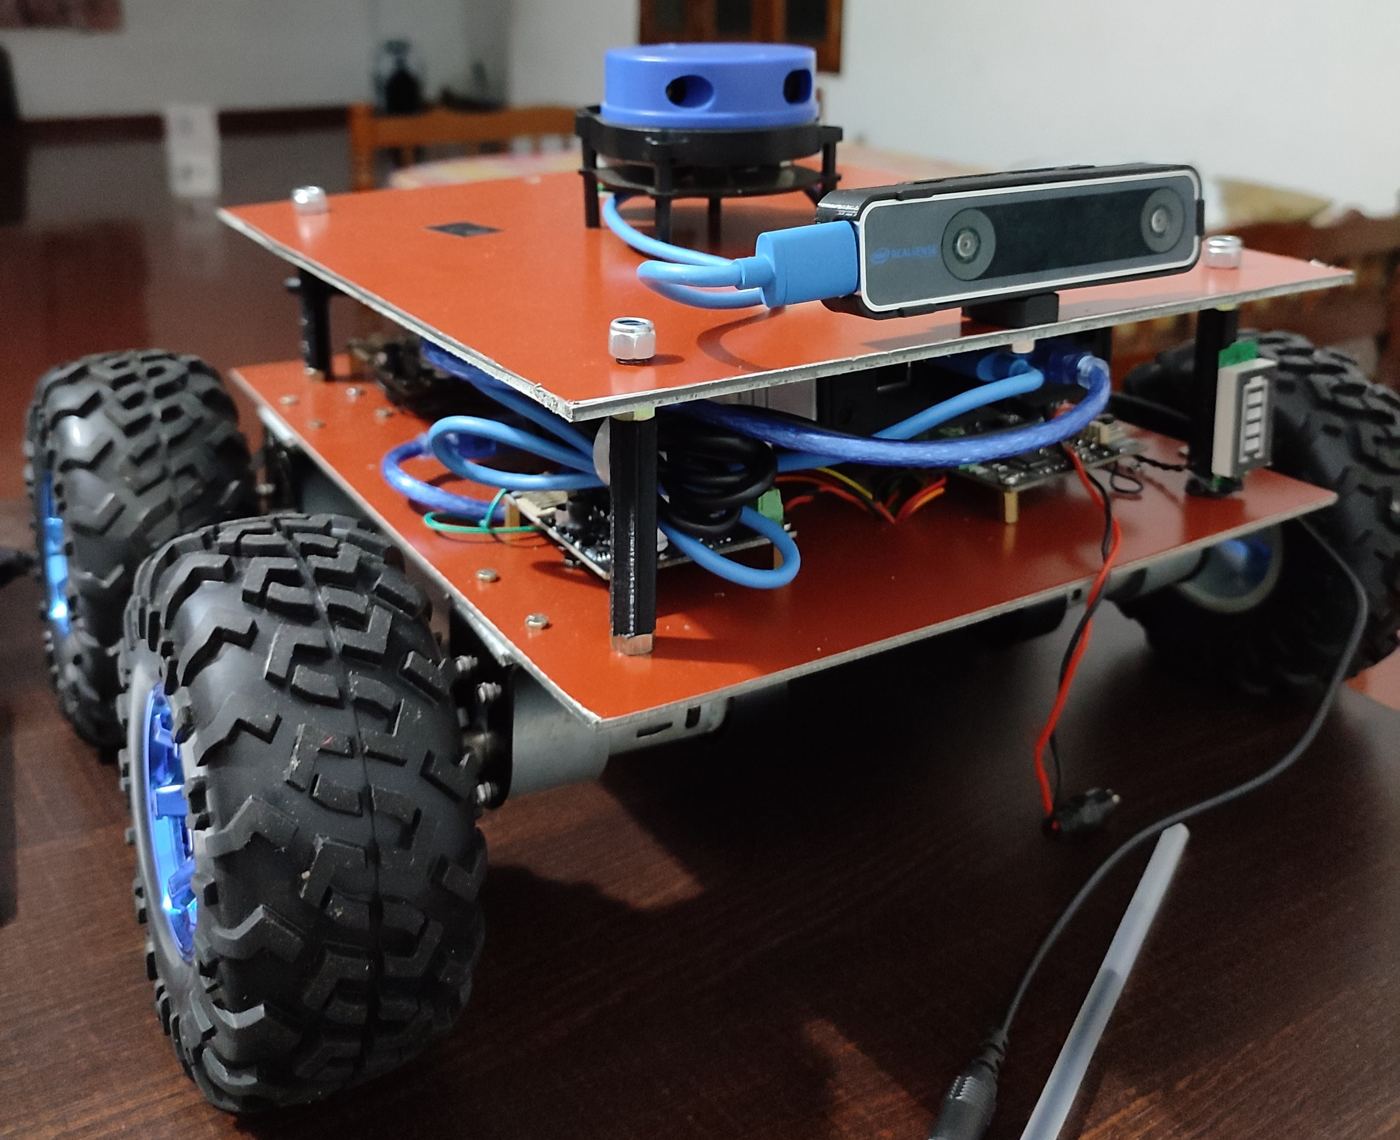
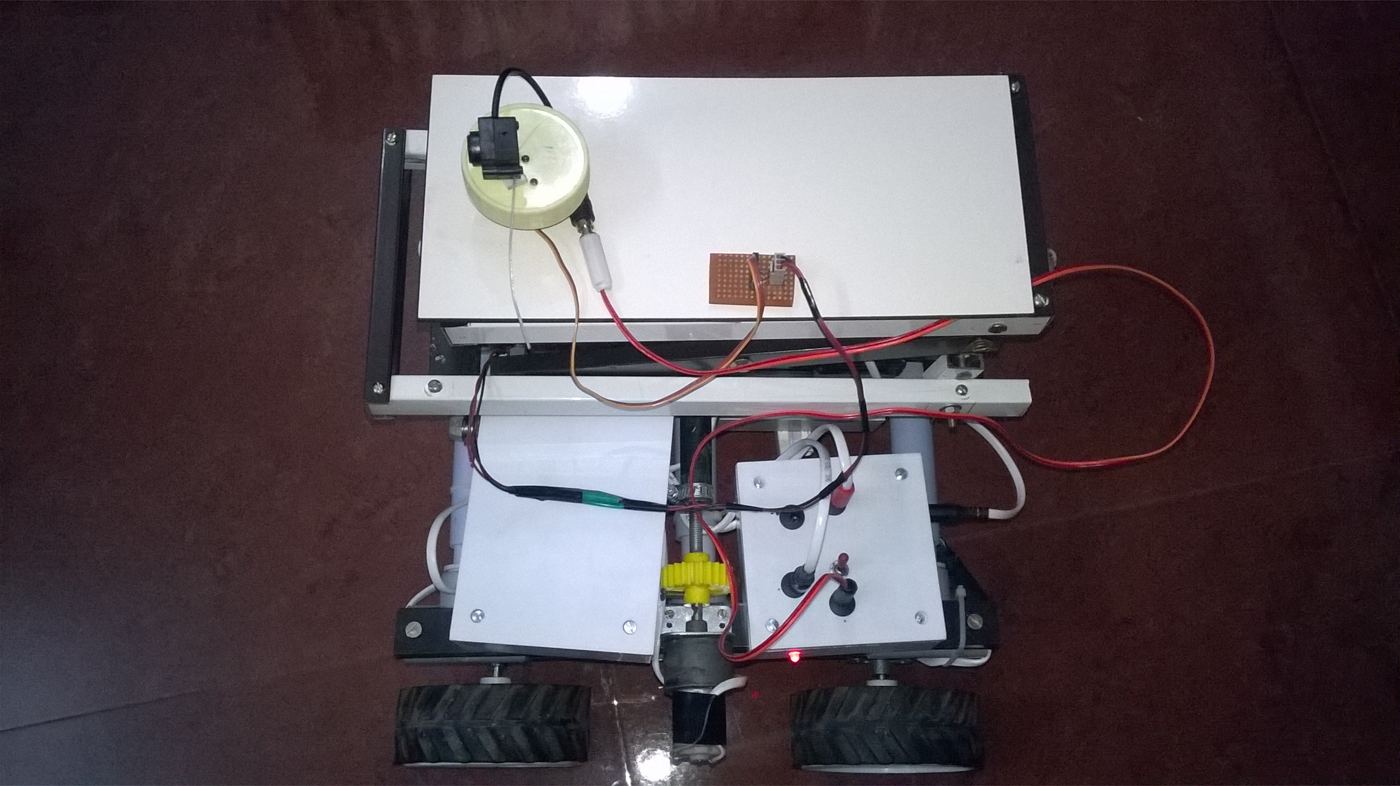
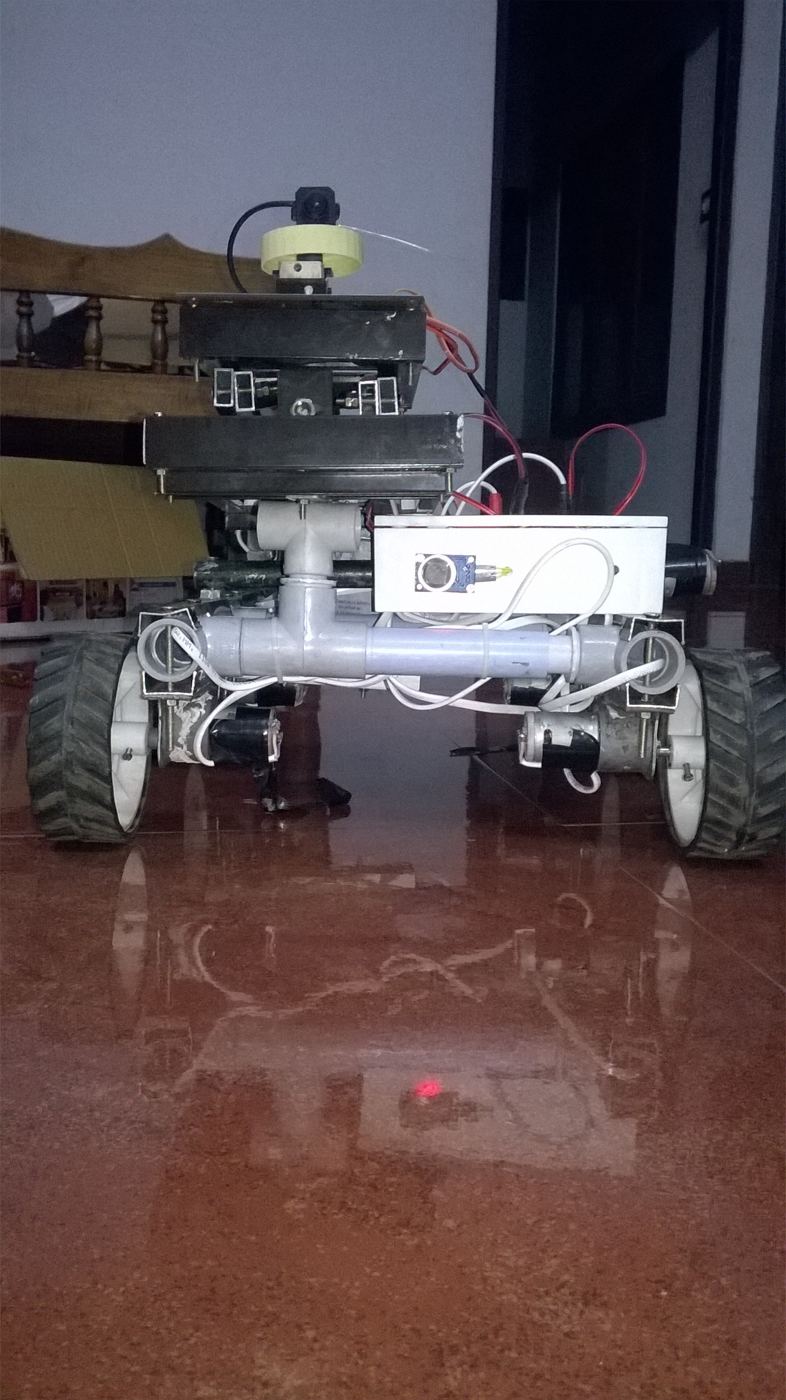
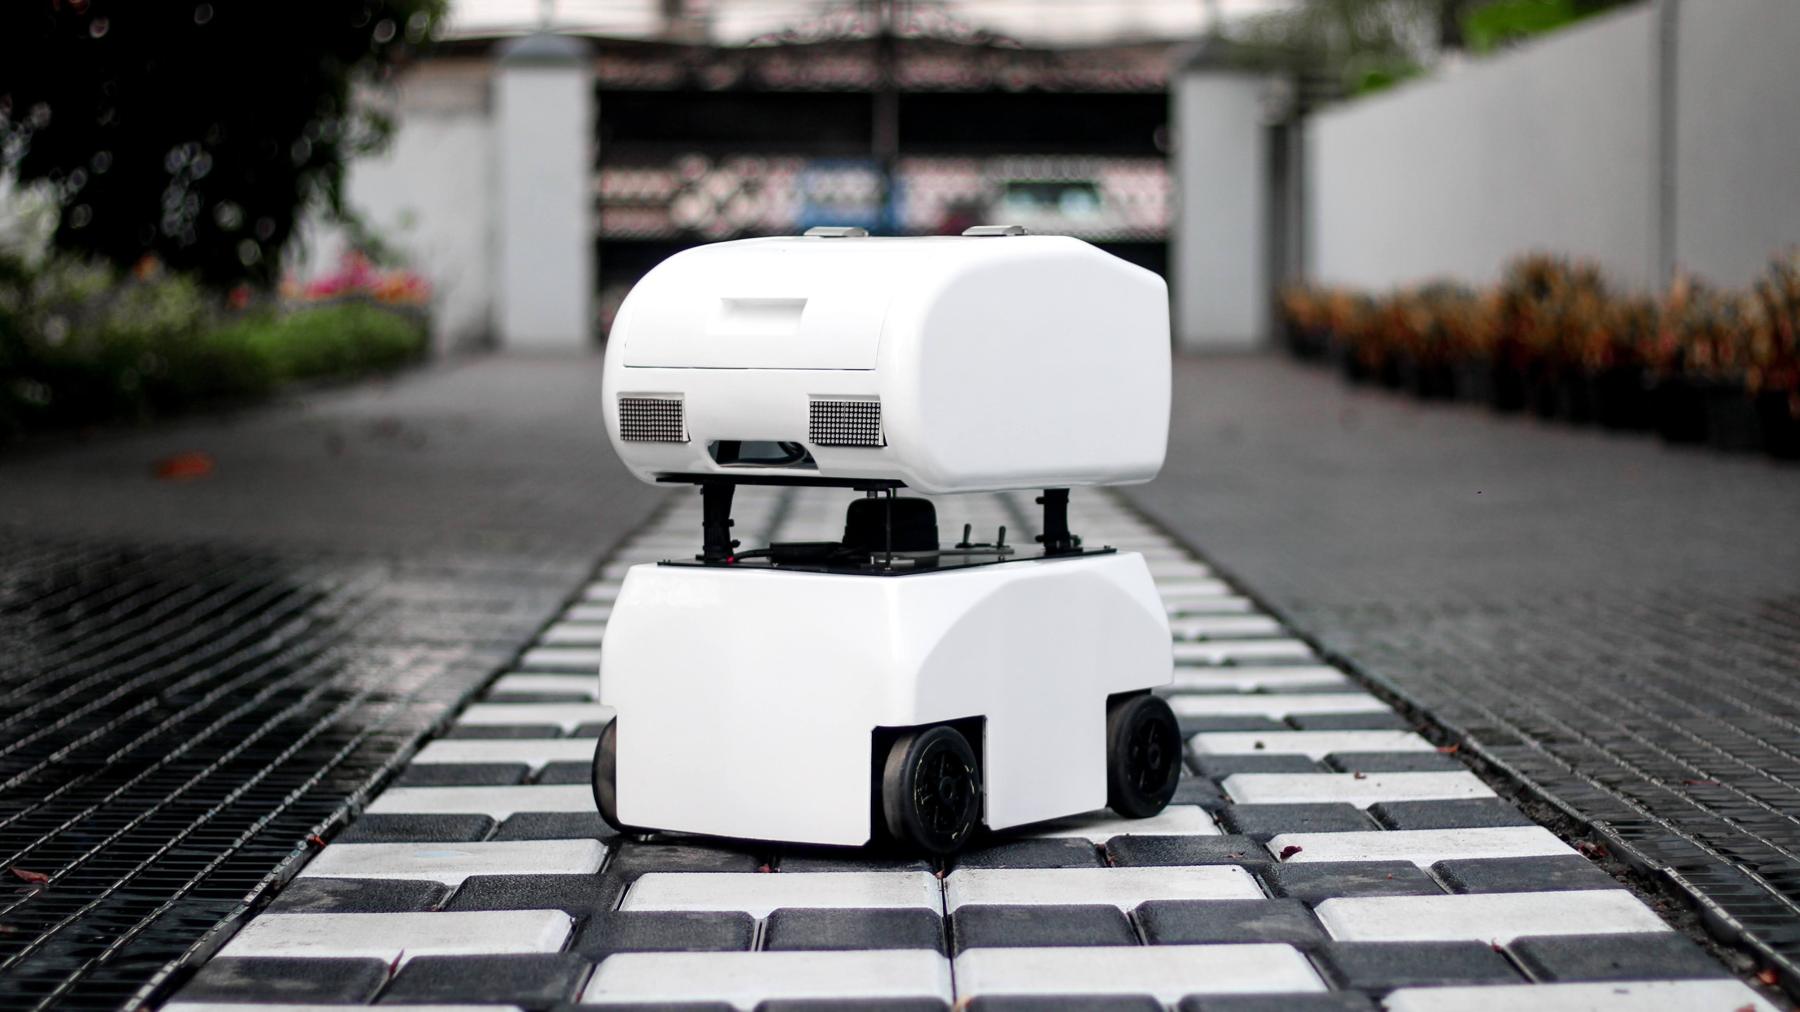
IEEE IAS CMD Student Robotics Demonstration ContestAn international contest run by the IEEE Industry Applications Society where student teams demo working robots. I won with the phase shifting all terrain rover.
Best Team
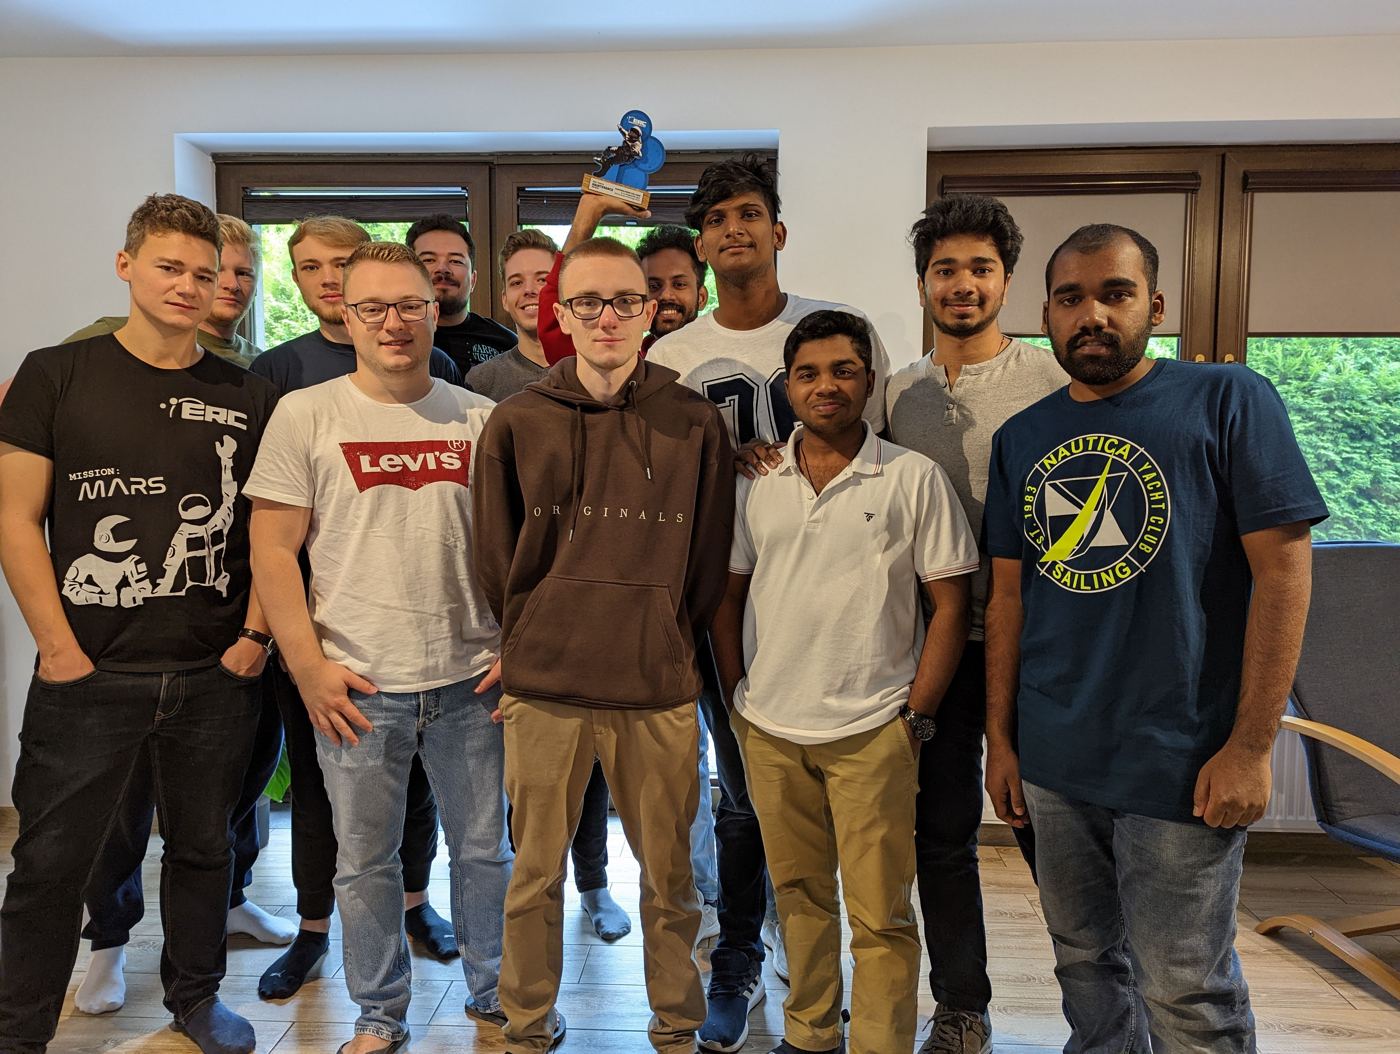
European Rover Challenge, Maintenance TaskOne of the largest space robotics competitions in the world, held in Poland, where student teams take Mars rover analogues through science, navigation and maintenance tasks.
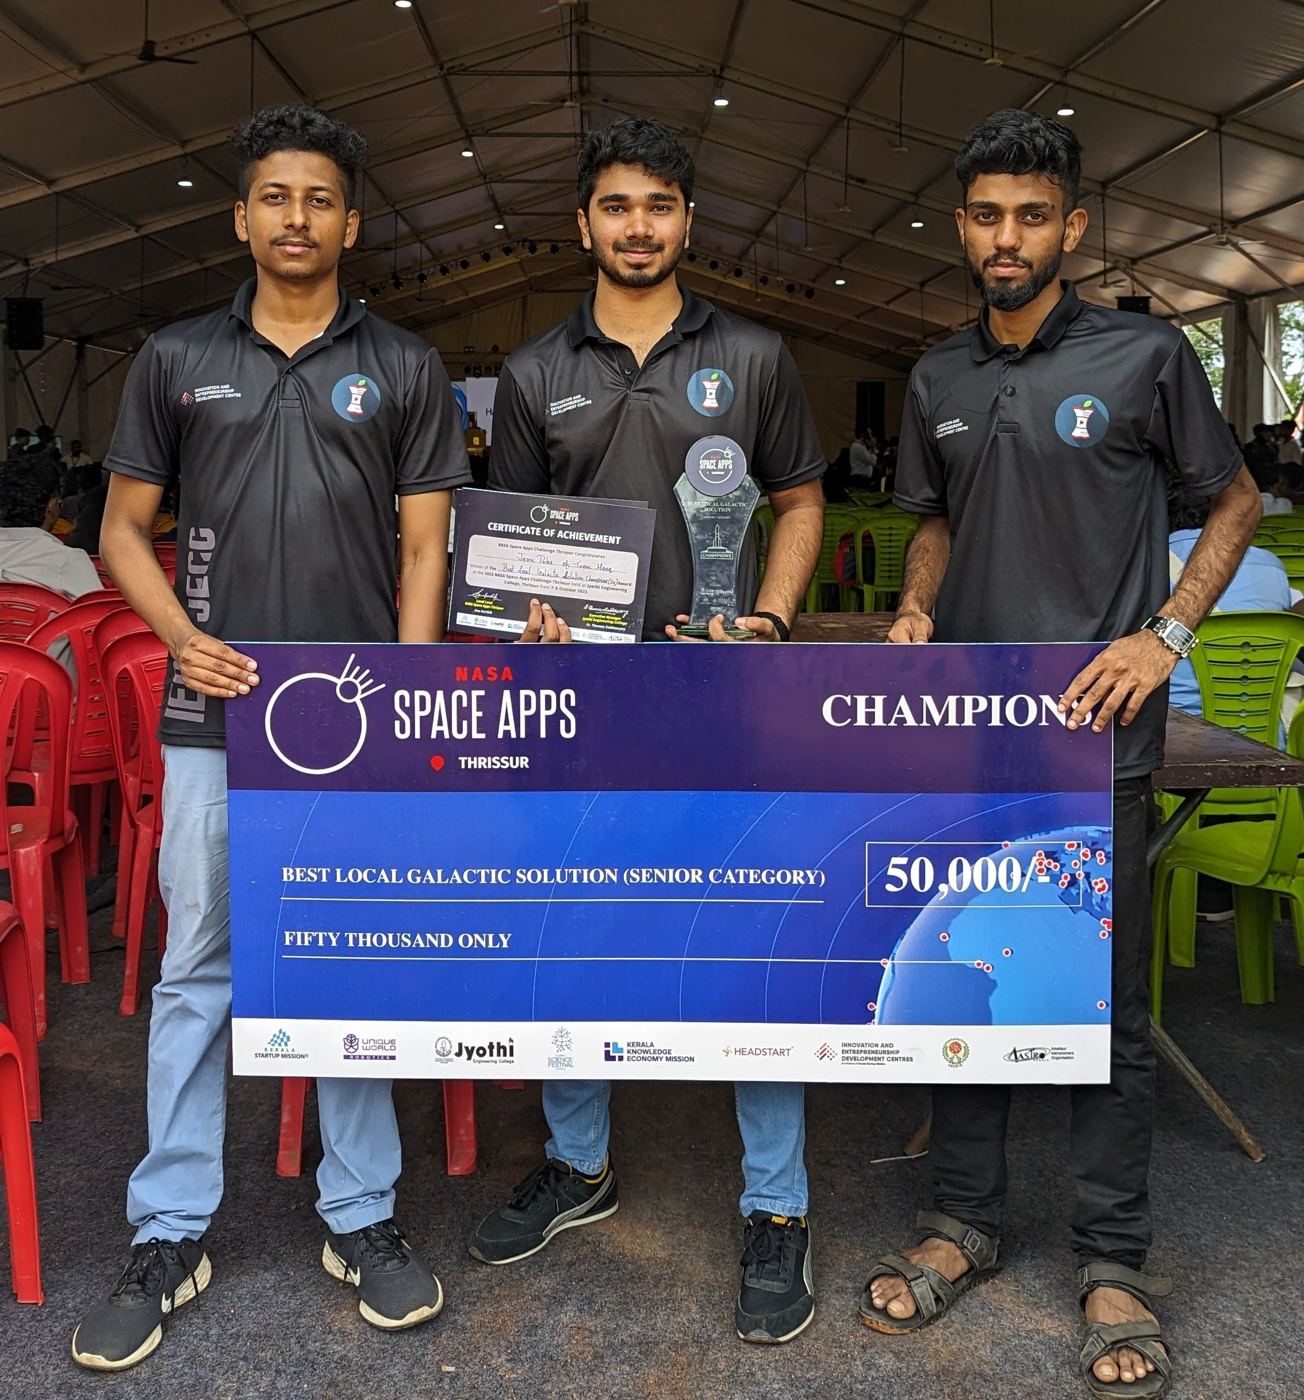
Champions
NASA Space Apps ChallengeNASA's international hackathon, run as hundreds of local events. Our team took Best Local Galactic Solution (senior category) at the Thrissur event.
Winner
Ottonomo 2022, TiHAN IIT HyderabadA grand challenge from TiHAN, IIT Hyderabad's autonomous navigation hub, looking for solutions to real bottlenecks in autonomous navigation.
Finalist
ARTPARK Robotics Challenge, IISc BangaloreRun by ARTPARK, the AI and robotics technology park at the Indian Institute of Science. Our team made the grand finale.
1st Prize
Swadarsh Autonomous Robot ChallengeA build and run challenge for autonomous robots, where our robot finished first.
06 · Teaching
+

Workshops on ROS, Nav2 and embedded robotics.

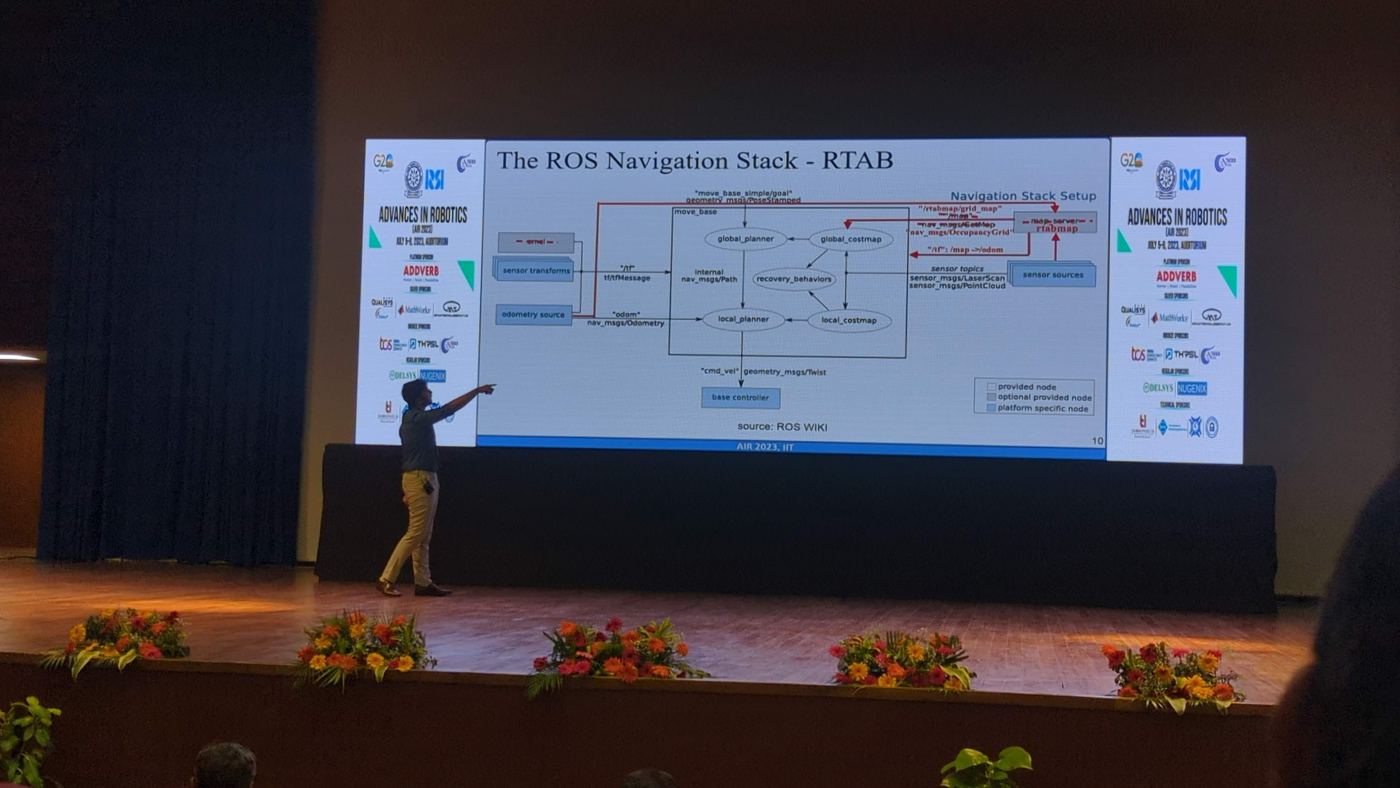
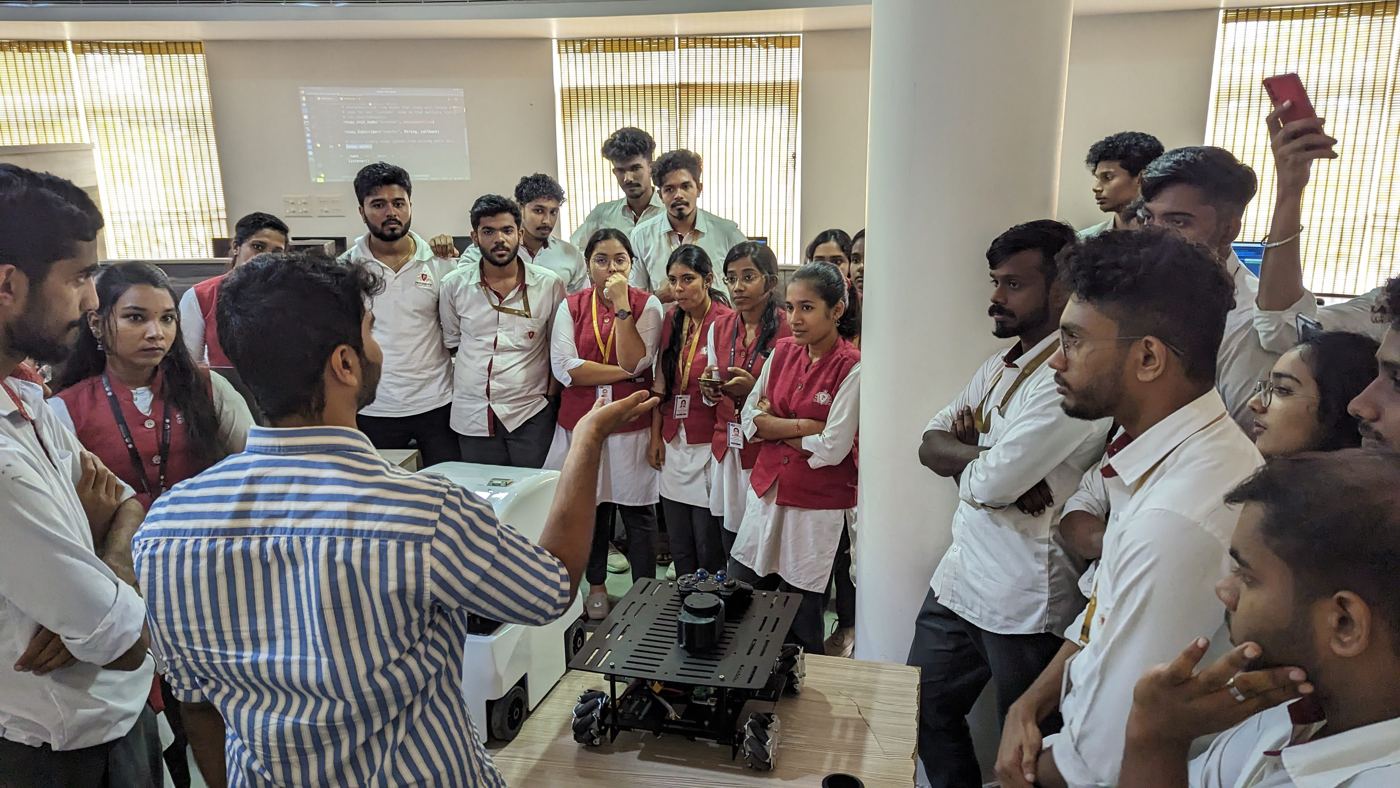
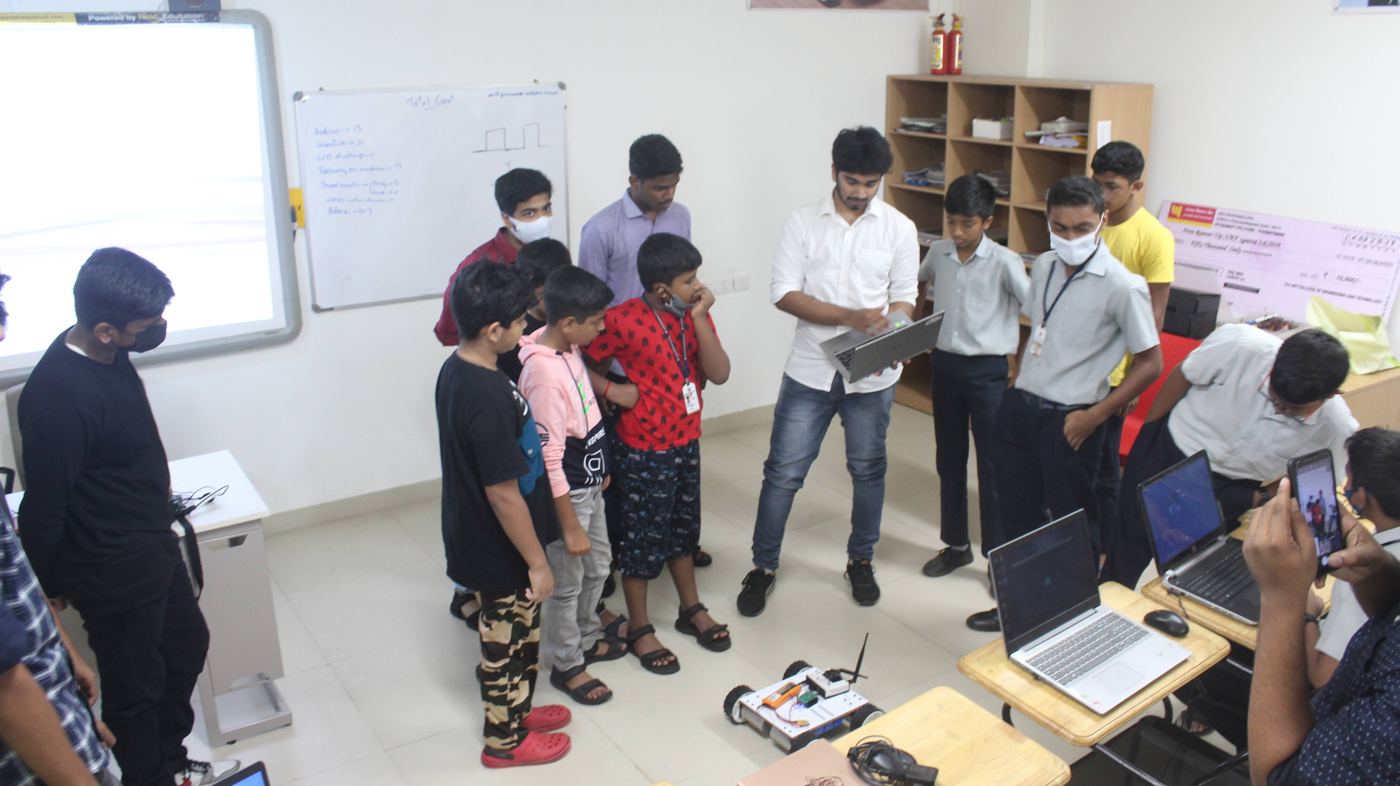
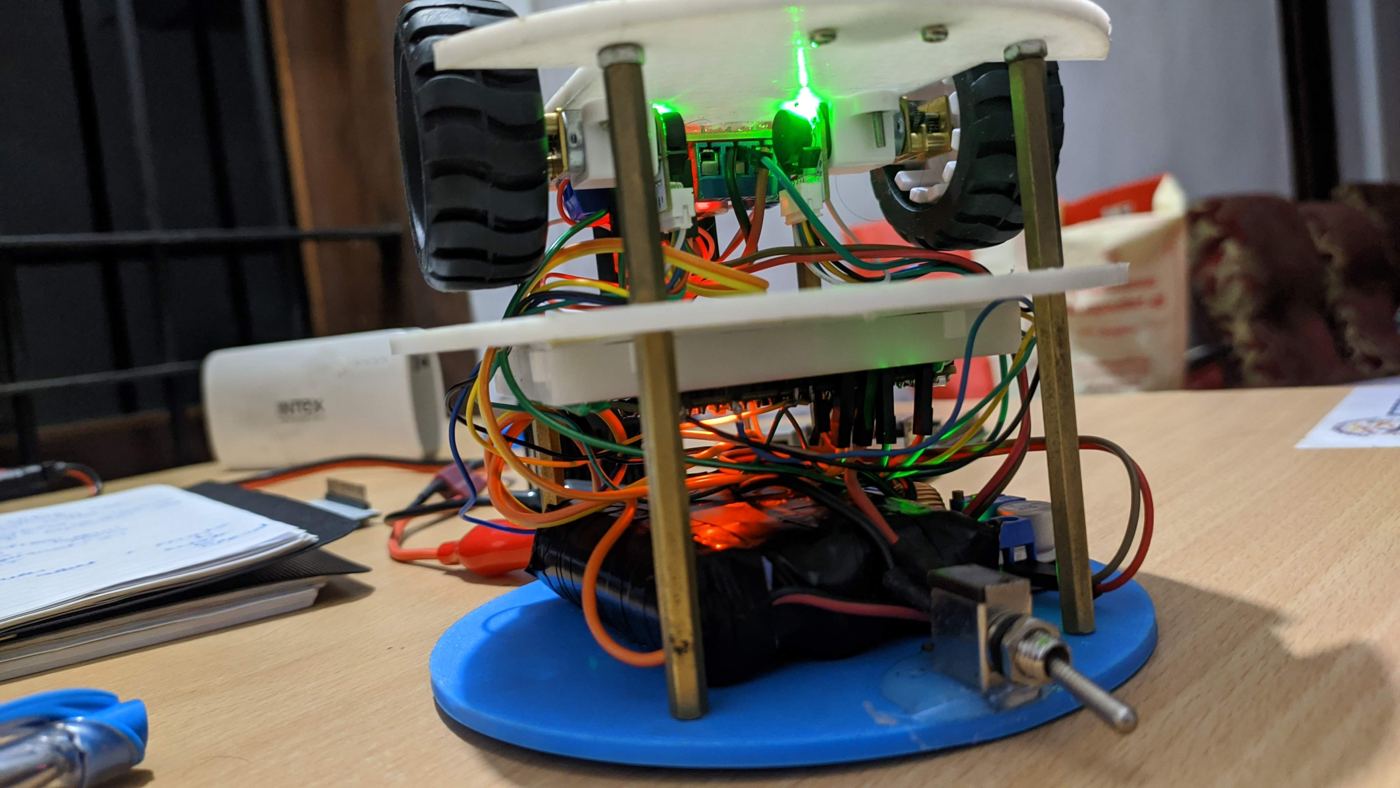
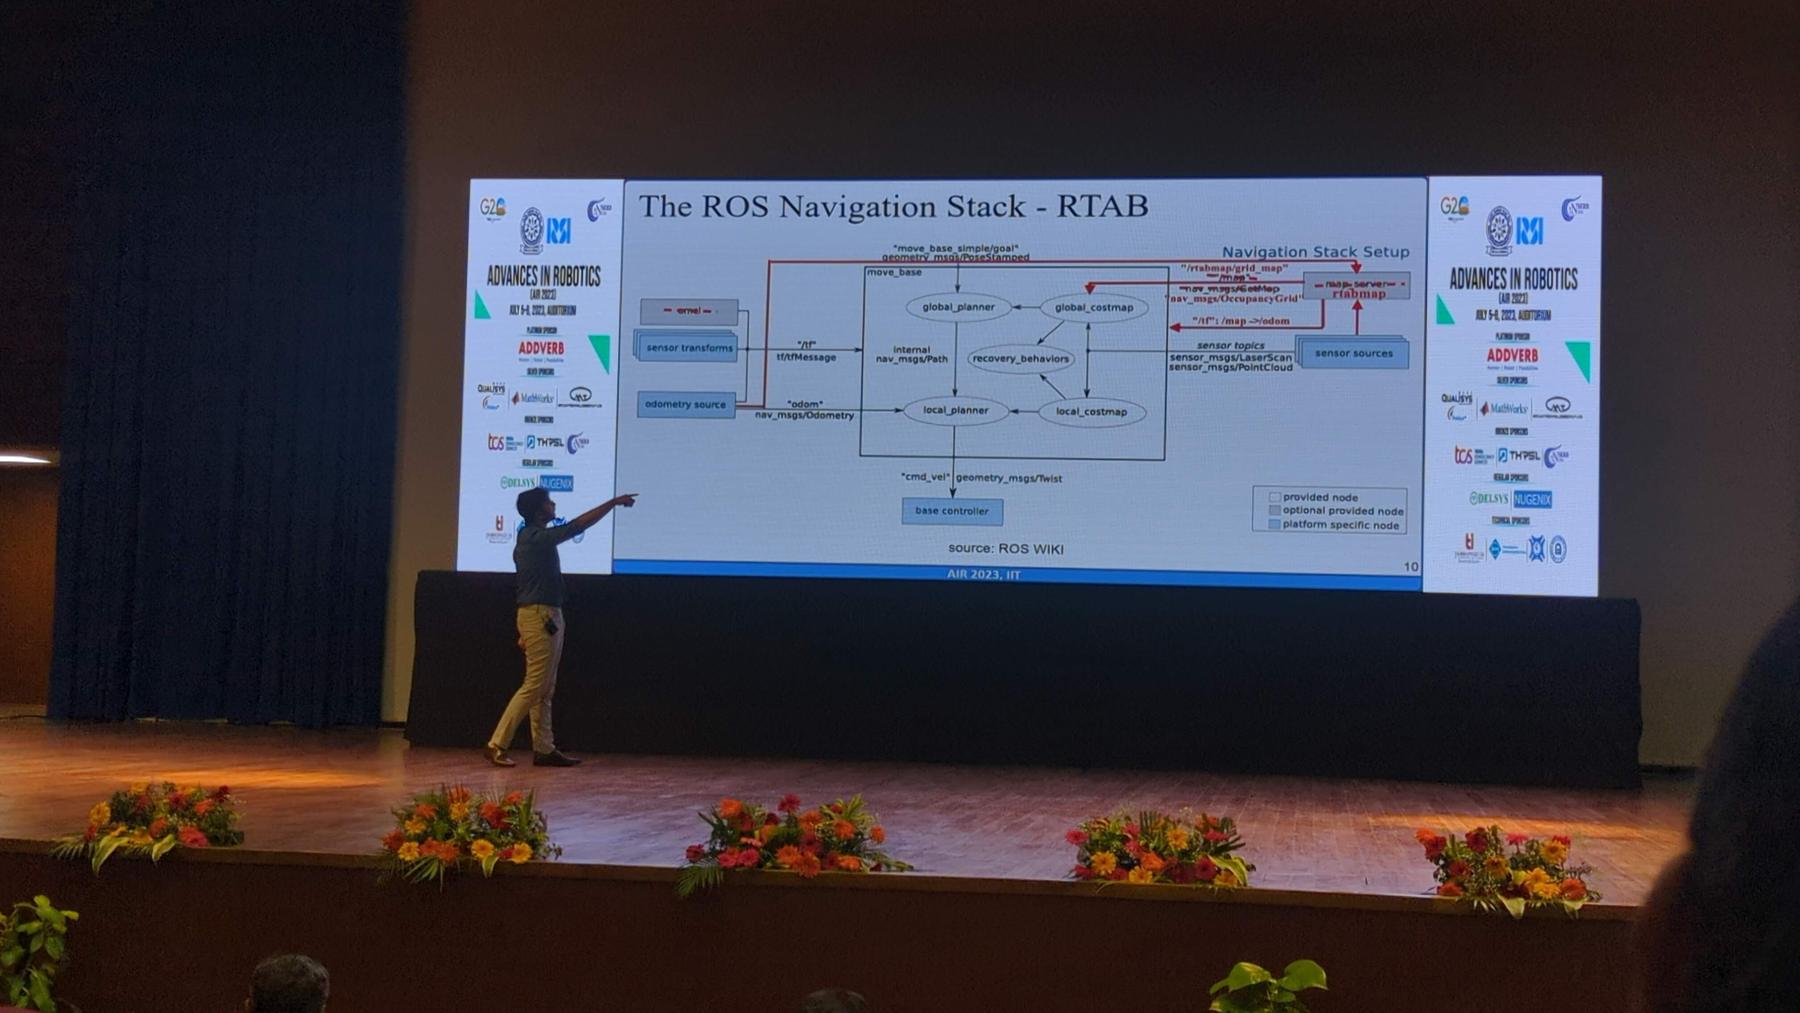
For students and faculty across Kerala, at IIT Ropar, at the UC Riverside BCOE Robotics Summer Camp, and as a TA for circuits and MATLAB at UCR. If it can be explained with a robot on the table, I would rather show it than slide it.

07 · Contact

Got a robot
that needs to
find its way?

jerinpeter@gmail.com
© 2026 Jerin Peter · built by hand, debugged at 2 amSan Francisco, CABack to top ↑